Publications

For a list of my featured publications, please scroll down the home page. For an exhaustive list that includes workshop papers, please see my CV.

* indicates that authors contributed equally
† indicates equal advising

Indicates featured/representative publications

2026

DREAMSTEER: Latent World Models Can Steer VLA Policies During Deployment Without Any Finetuning

Hanchen Cui ,  Sergio Arnaud ,  Arjun Majumdar ,  Daniel Dugas ,  Elie Aljalbout ,  Karthik Desingh † ,  Krishna Murthy Jatavallabhula † ,  and Franziska Meier †

arXiv preprint 2026

RAIDEN: A Toolkit for Policy Learning with YAM Bimanual Robot Arms

Shun Iwase ,  Patrick Miller ,  Jonathan Yao ,  Krishna Murthy Jatavallabhula ,  and Sergey Zakharov

Open-source toolkit 2026

2025

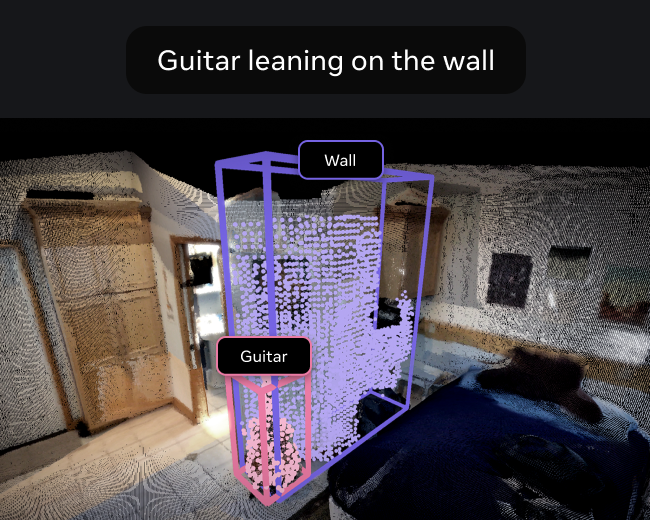
An image showing the output text labels from the locate 3d model.

Locate 3D: Real-World Object Localization via Self-Supervised Learning in 3D

Sergio Arnaud ,  Paul McVay ,  Ada Martin ,  Arjun Majumdar ,  Krishna Murthy Jatavallabhula ,  Phillip Thomas ,  Ruslan Partsey ,  Daniel Dugas ,  Abha Gejji ,  Alexander Sax ,  Vincent-Pierre Berges ,  Mikael Henaff ,  Ayush Jain ,  Ang Cao ,  Ishita Prasad ,  Mrinal Kalakrishnan ,  Michael Rabbat ,  Nicolas Ballas ,  Mido Assran ,  Oleksandr Maksymets ,  Aravind Rajeswaran ,  and Franziska Meier

ICML 2025

A gif showing a robot separating granular media into two piles.

Gaussian Splatting Visual MPC for Granular Media Manipulation

Wei-Cheng Tseng ,  Ellina Zhang ,  Krishna Murthy Jatavallabhula ,  and Florian Shkurti

ICRA 2025

ICRA

ConceptAgent: LLM-Driven Precondition Grounding and Tree Search for Robust Task Planning and Execution

Corban Rivera ,  Grayson Byrd ,  William Paul ,  Tyler Feldman ,  Meghan Booker ,  Emma Holmes ,  David Handelman ,  Bethany Kemp ,  Andrew Badger ,  Aurora Schmidt ,  Krishna Murthy Jatavallabhula ,  Celso M. de Melo ,  Lalithkumar Seenivasan ,  Mathias Unberath ,  and Rama Chellappa

ICRA 2025

RA-L

STAMP: Differentiable Task and Motion Planning via Stein Variational Gradient Descent

Yewon Lee ,  Andrew Z. Li ,  Philip Huang ,  Eric Heiden ,  Krishna Murthy Jatavallabhula ,  Fabian Damken ,  Kevin Smith ,  Derek Nowrouzezahrai ,  Fabio Ramos ,  and Florian Shkurti

IEEE RA-L 2025

2024

A gif depicting the 3D mapping process implemented as part of SplaTAM.

SplaTAM:Splat, Track, and Map 3D Gaussians for Dense RGB-D SLAM

Nikhil Keetha ,  Jay Karhade ,  Krishna Murthy Jatavallabhula ,  Gengshan Yang ,  Sebastian Scherer ,  Deva Ramanan ,  and Jonathon Luiten

CVPR 2024

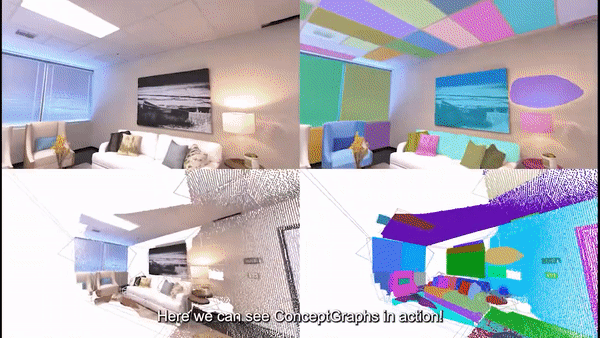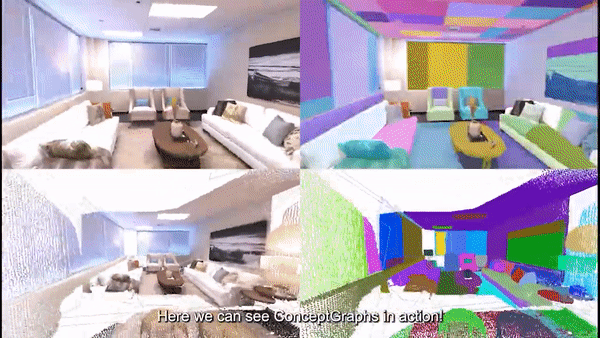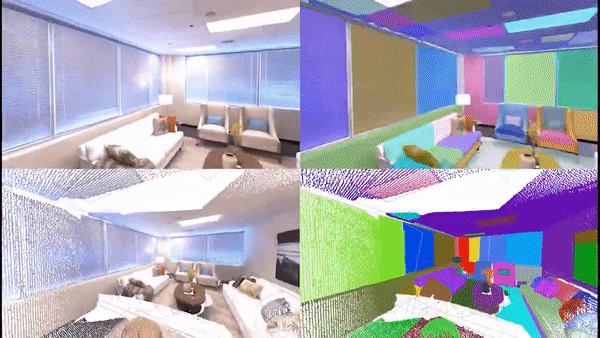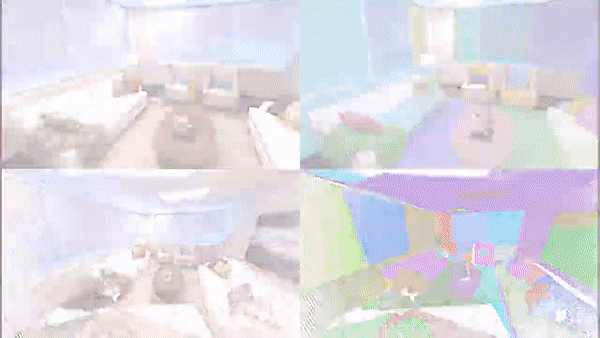
A gif depicting the 3D mapping process implemented as part of ConceptGraphs.

Qiao Gu * ,  Alihusein Kuwajerwala * ,  Sacha Morin * ,  Krishna Murthy Jatavallabhula * ,  Bipasha Sen ,  Aditya Agarwal ,  Corban Rivera ,  William Paul ,  Kirsty Ellis ,  Rama Chellappa ,  Chuang Gan ,  Celso Miguel de Melo ,  Joshua B. Tenenbaum ,  Antonio Torralba ,  Florian Shkurti ,  and Liam Paull

ICRA 2024

An example output instance localization image of the iML system implemented on a living room scene from the Replica dataset.

iML: Efficient 3D Instance Mapping and Localization

George Tang ,  Antonio Torralba ,  and Krishna Murthy Jatavallabhula

ICRA 2024

A robot gently stacking two light-weight objects using tactile sensing and our proposed method.

Tactile Estimation of Extrinsic Contact Patch for Stable Placement

Kei Ota ,  Devesh Jha ,  Krishna Murthy Jatavallabhula ,  Asako Kanezaki ,  and Joshua B. Tenenbaum

ICRA 2024

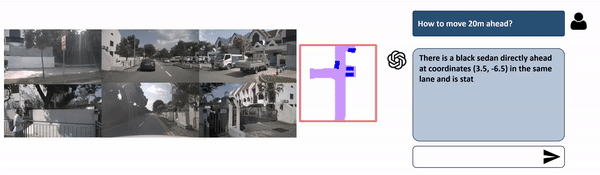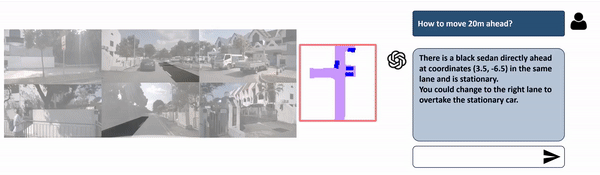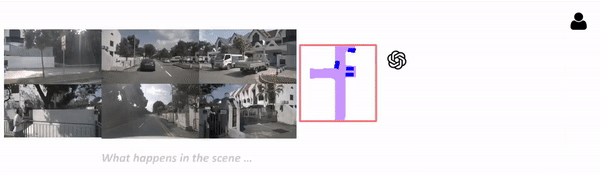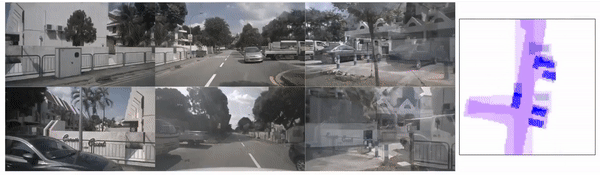
A gif depicting a conversation with the Talk2BEV system. The user asks how they should move 20 m forward, and the system responds by saying there is a vehicle in front that we may need to pass by changing to the other lane.

Talk2BEV: Language-enhanced Bird’s-eye View Maps for Autonomous Driving

Vikrant Dewangan ,  Tushar Choudhary * ,  Shivam Chandhok * ,  Shubham Priyadarshan ,  Anushka Jain ,  Arun Singh ,  Siddharth Srivastava ,  Krishna Murthy Jatavallabhula * ,  and Madhava Krishna

ICRA 2024

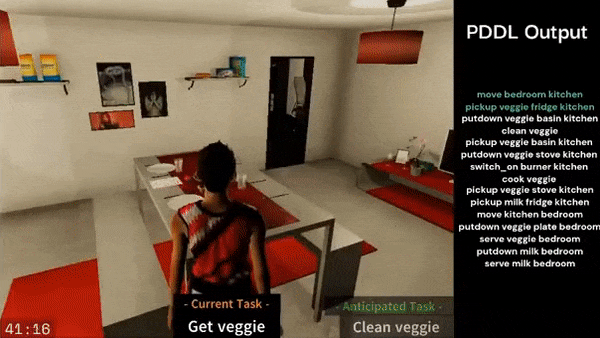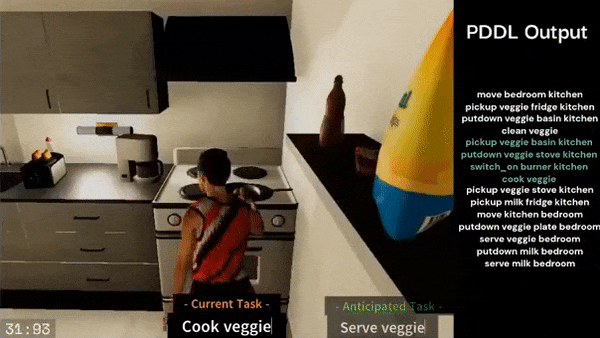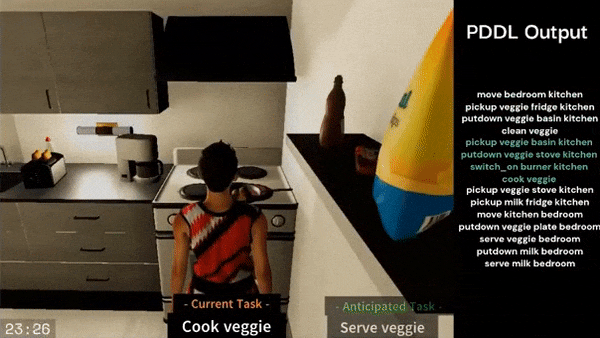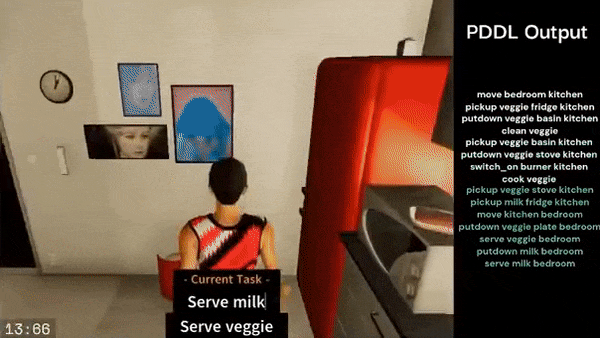
A gif depicting the task anticipation and execution process on a simulated household agent in the VirtualHome environment.

Anticipate & Act: Integrating LLMs and Classical Planning for Efficient Task Execution in Household Environments

Raghav Arora ,  Shivam Singh ,  Karthik Swaminathan ,  Ahana Datta ,  Snehasis Banerjee ,  Brojeshwar Bhowmick ,  Krishna Murthy Jatavallabhula ,  Mohan Sridharan ,  and Madhava Krishna

ICRA 2024

A gif depicting the Follow Anything system tracking and following an object in real-time.

Follow Anything: Open-set detection, tracking, and following in real-time

Alaa Maalouf ,  Ninad Jadhav ,  Krishna Murthy Jatavallabhula ,  Makram Chahine ,  Daniel M Vogt ,  Robert J Wood ,  Antonio Torralba ,  and Daniela Rus

Robotics and Automation Letters 2024

2023

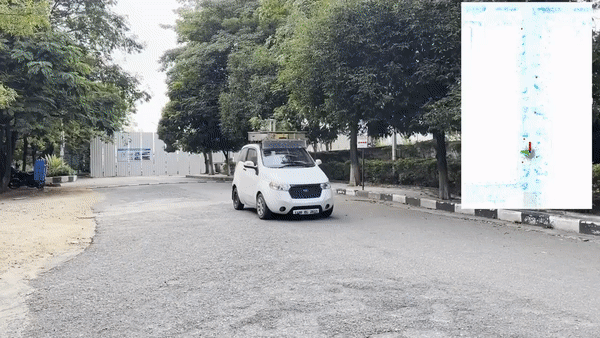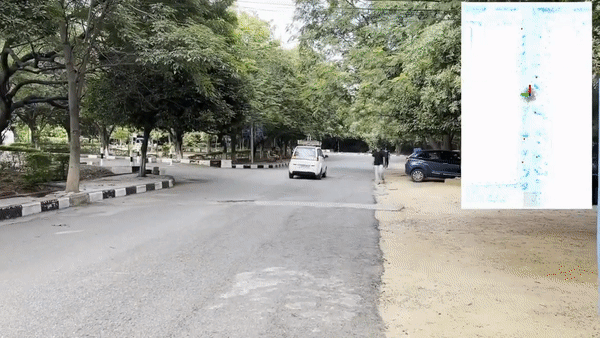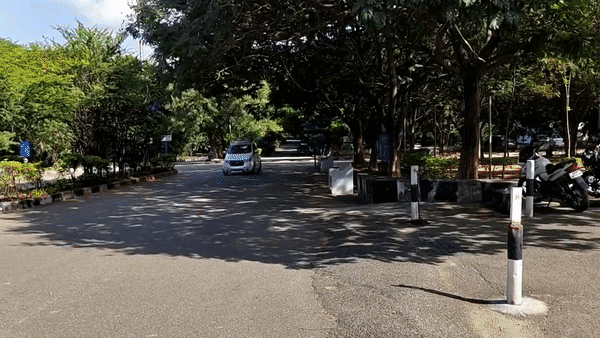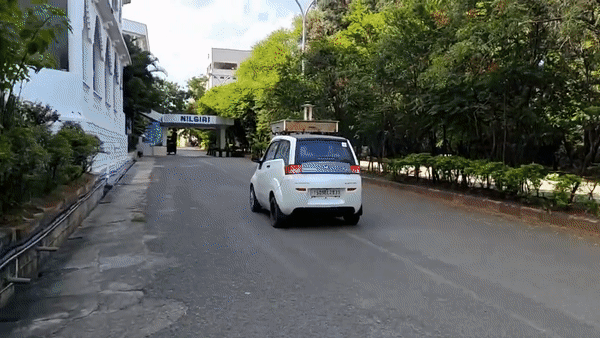
Our system, ALT-Pilot, autonomously driving to a language-specified destination.

Mohd Omama ,  Pranav Inani ,  Pranjal Paul ,  Sarat Chandra Yellapragada ,  Krishna Murthy Jatavallabhula * ,  Sandeep Chinchali * ,  and Madhava Krishna

preprint 2023

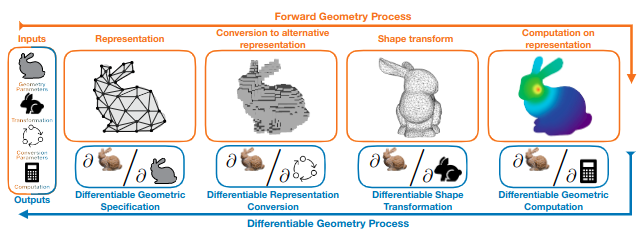
Differentiable Visual Computing for Inverse Problems and Machine Learning

Andrew Spielberg ,  Cengiz Oztireli ,  Derek Nowrouzezahrai ,  Fangcheng Zhong ,  Konstantinos Rematas ,  Krishna Murthy Jatavallabhula ,  and Tzu-Mao Li

Nature Machine Intelligence 2023

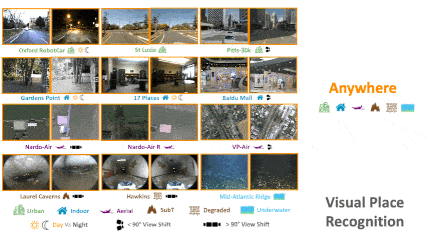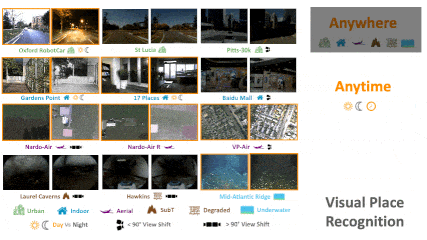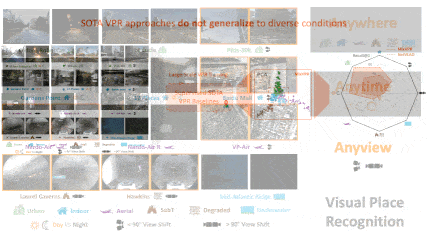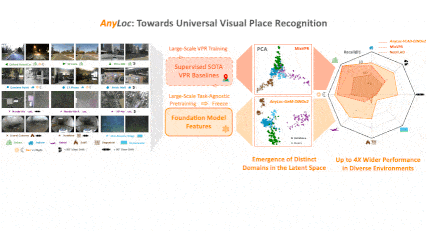
A gif depicting the various kinds of scenes (outdoors, indoors, underwater, aerial) that AnyLoc was deployed in.

AnyLoc: Towards Universal Visual Place Recognition

Nikhil Keetha * ,  Avneesh Mishra * ,  Jay Karhade * ,  Krishna Murthy Jatavallabhula ,  Sebastian Scherer ,  Madhava Krishna ,  and Sourav Garg

Robotics and Automation Letters (and ICRA 2024) 2023

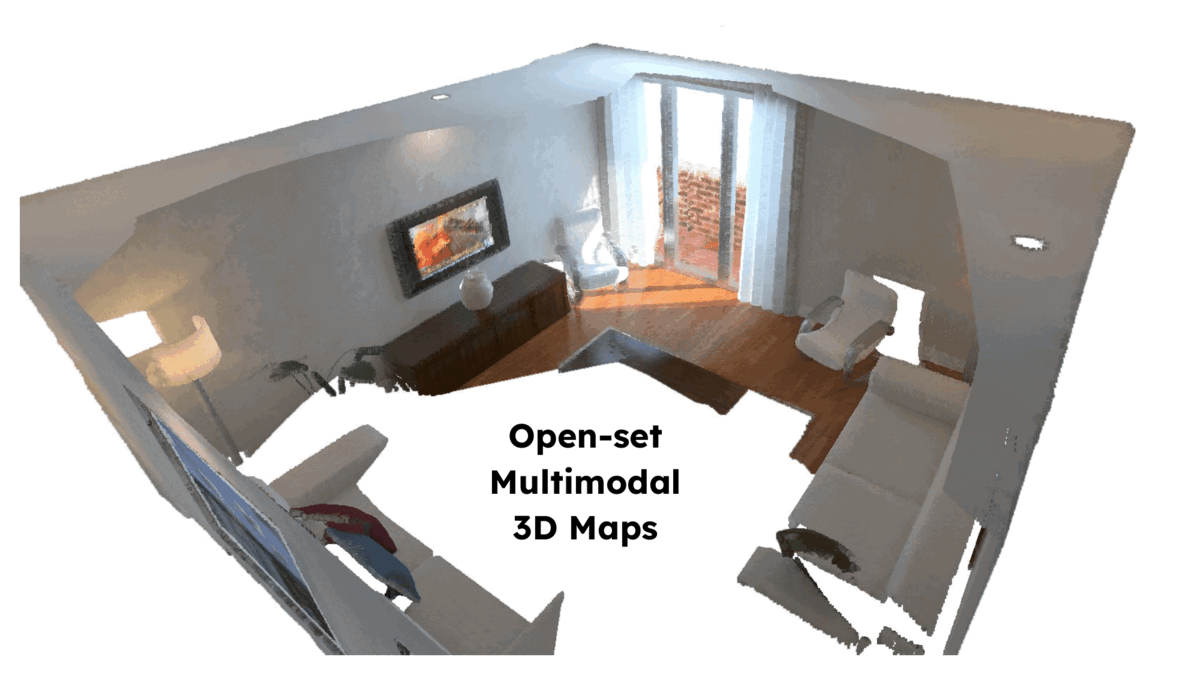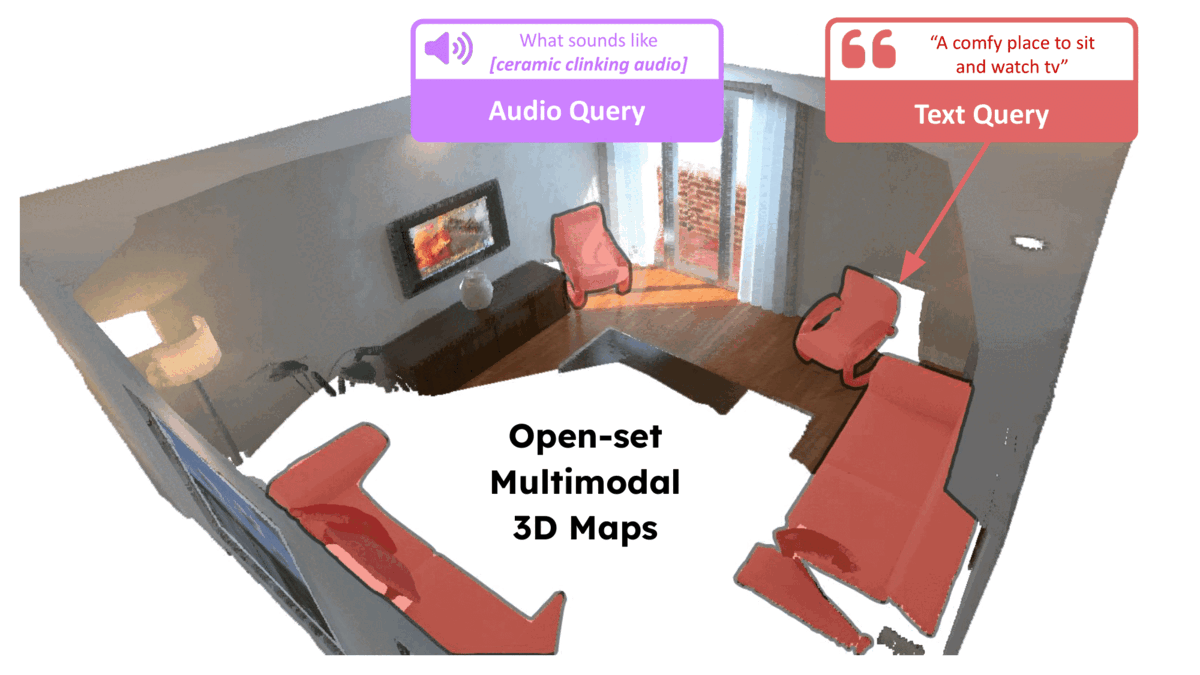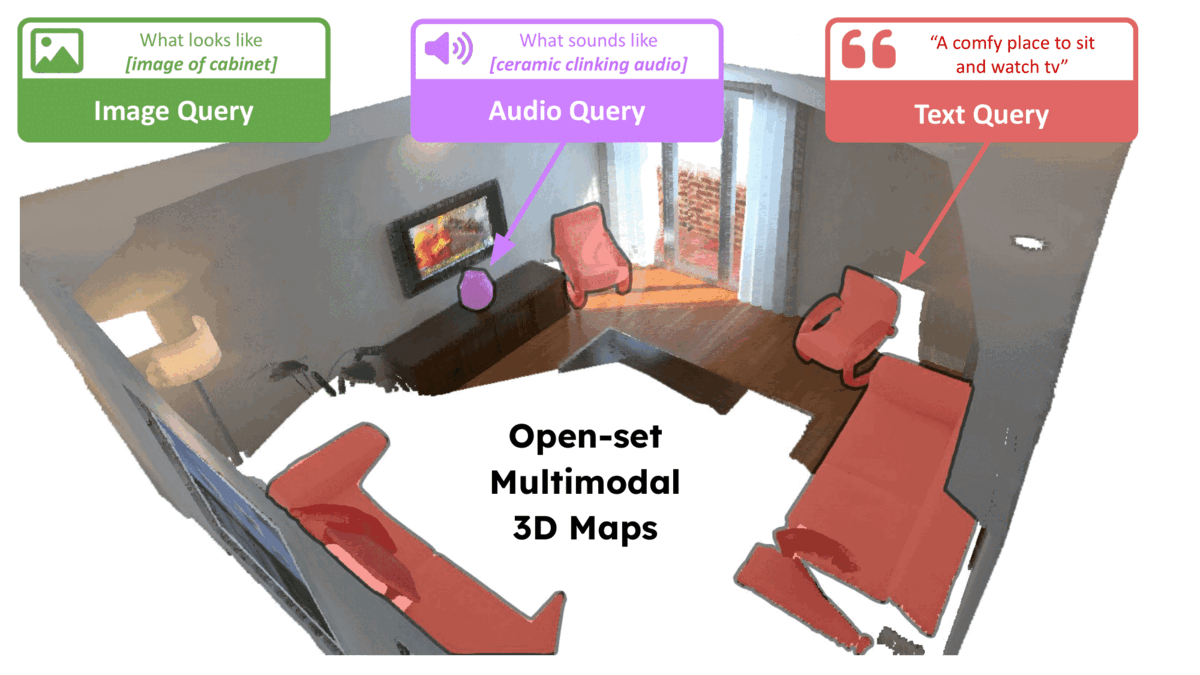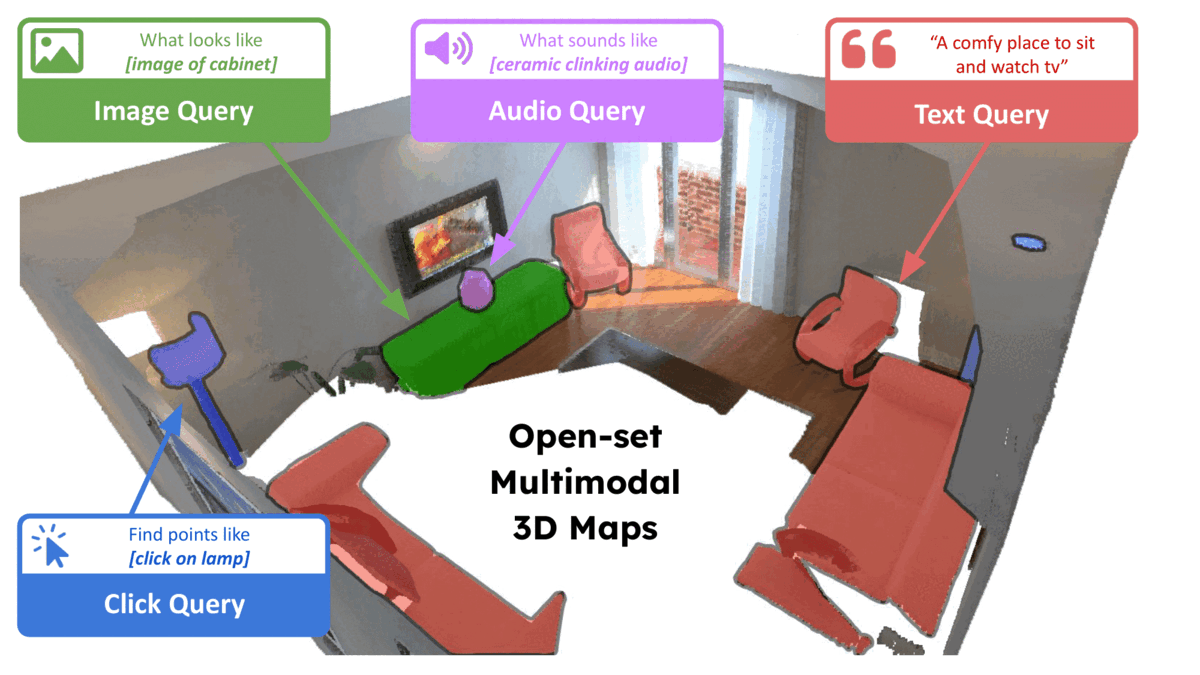
A gif depicting the types of multimodal queries (text, image, audio, click) supported by ConceptFusion.

Krishna Murthy Jatavallabhula ,  Alihusein Kuwajerwala ,  Qiao Gu ,  Mohd Omama ,  Tao Chen ,  Shuang Li ,  Ganesh Iyer ,  Soroush Saryazdi ,  Nikhil Keetha ,  Ayush Tewari ,  Joshua B. Tenenbaum ,  Celso Miguel de Melo ,  Madhava Krishna ,  Liam Paull ,  Florian Shkurti ,  and Antonio Torralba

RSS 2023

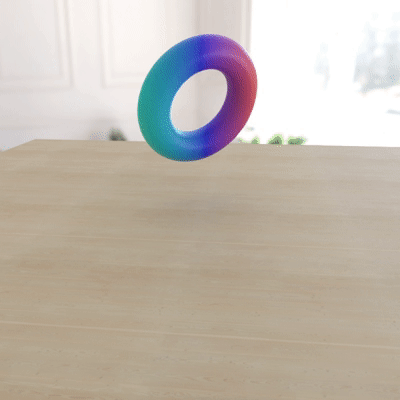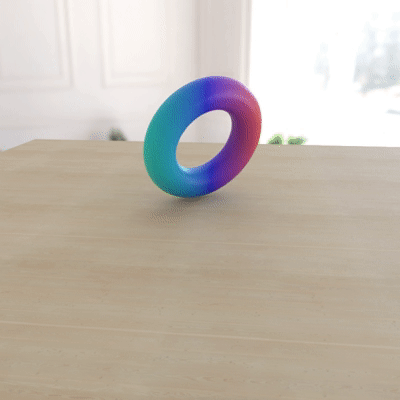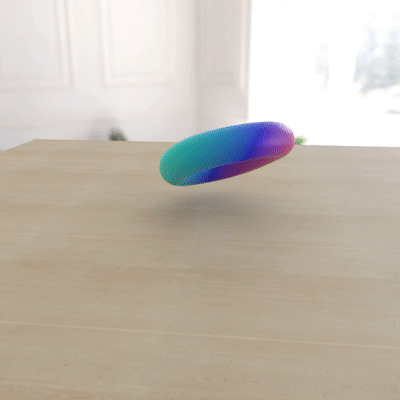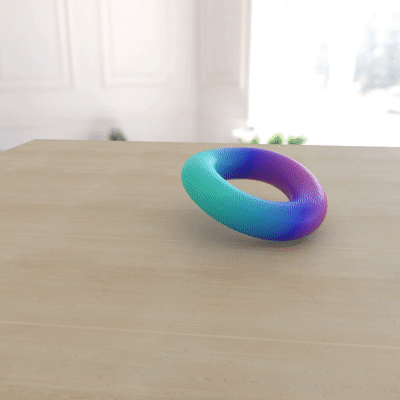
A demo from PAC-NeRF – estimating the geometry and physical properties of a deformable torus

PAC-NeRF: Physics Augmented Continuum Neural Radiance Fields for Geometry-Agnostic System Identification

Xuan Li ,  Yi-Ling Qiao ,  Peter Yichen Chen ,  Krishna Murthy Jatavallabhula ,  Ming Lin ,  Chenfanfu Jiang ,  and Chuang Gan

ICLR 2023

Notable top 25 (top 25 percent of accepted submissions)

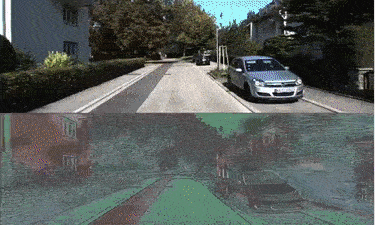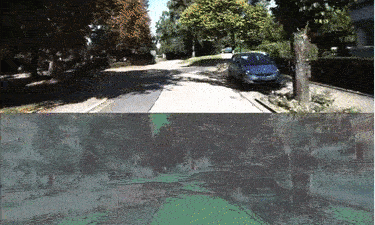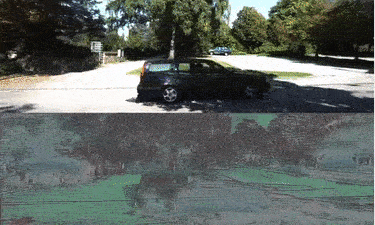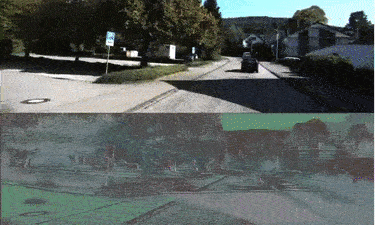
A gif depicting the uncertainty estimation results over an autonomous driving sequence from KITTI.

Learning Correspondence Uncertainty via Differentiable Nonlinear Least Squares

Dominik Muhle ,  Lukas Koestler ,  Krishna Murthy Jatavallabhula ,  and Daniel Cremers

CVPR 2023

2022

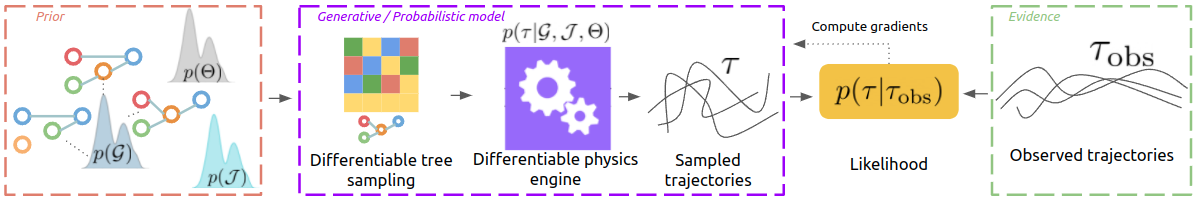
A pipeline figure for the Bayesian Object Models work

Krishna Murthy Jatavallabhula ,  Miles Macklin ,  Dieter Fox ,  Animesh Garg ,  and Fabio Ramos

CoRL 2022

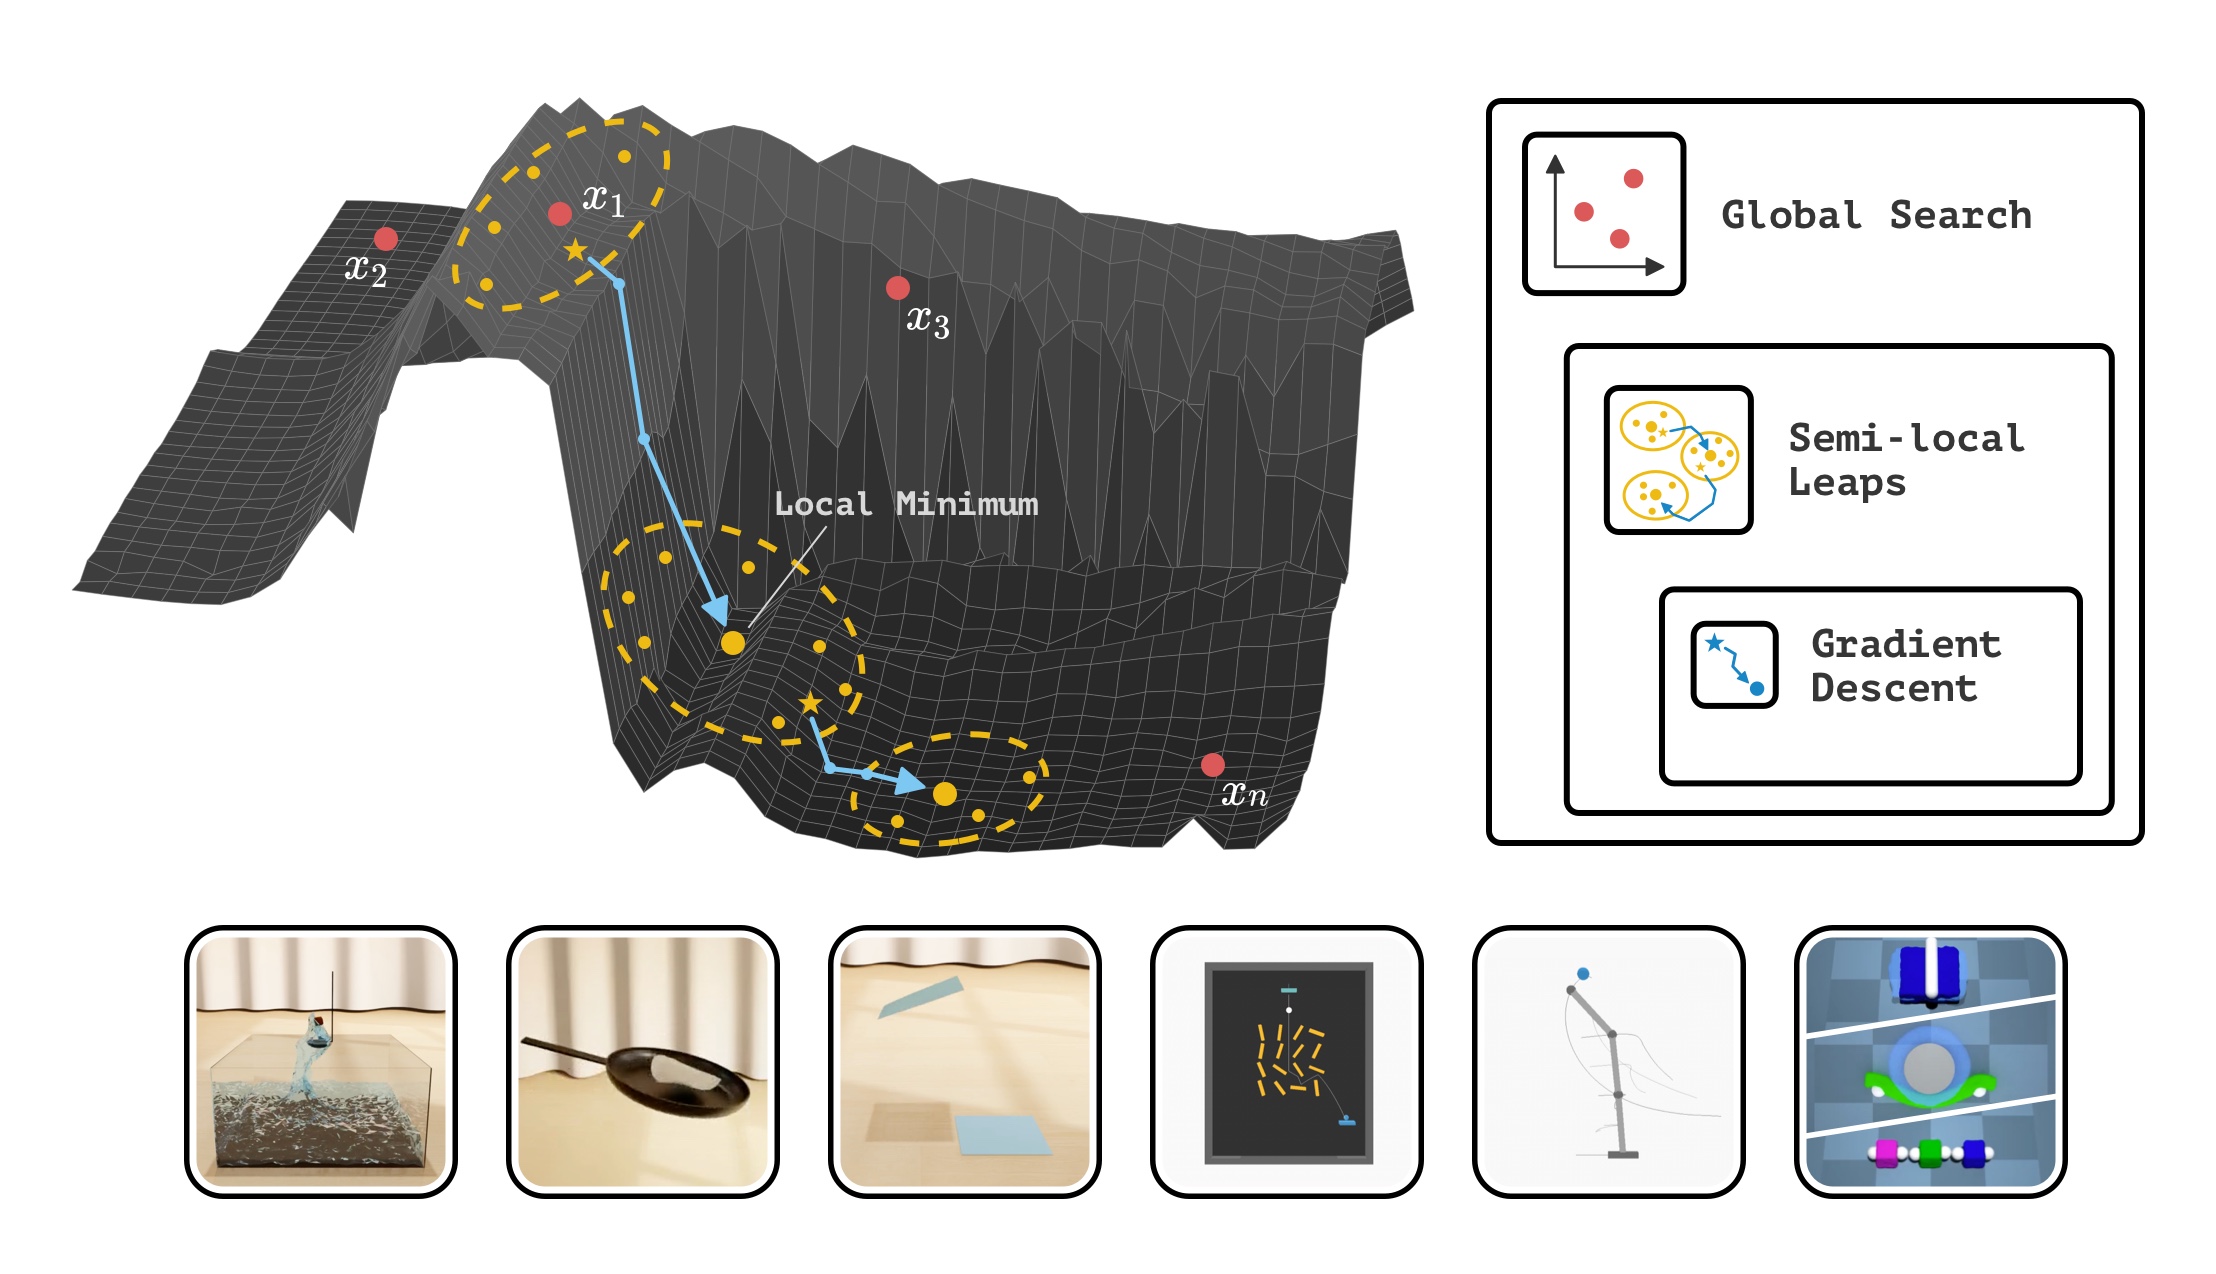
A didactic figure explaining our core algorithm, and showing some environments we use for evaluation.

Rethinking Optimization with Differentiable Simulation from a Global Perspective

Rika Antonova * ,  Jingyun Yang * ,  Krishna Murthy Jatavallabhula ,  and Jeannette Bohg

CoRL 2022

Oral presentation (top 6.5 percent of submissions)

Sample object detection (and uncertainty estimates) from our approach.

f -Cal: Calibrated aleatoric uncertainty estimation from neural networks for robot perception

Dhaivat Bhatt * ,  Kaustubh Mani * ,  Dishank Bansal ,  Hanju Lee ,  Krishna Murthy Jatavallabhula ,  and Liam Paull

ICRA 2022

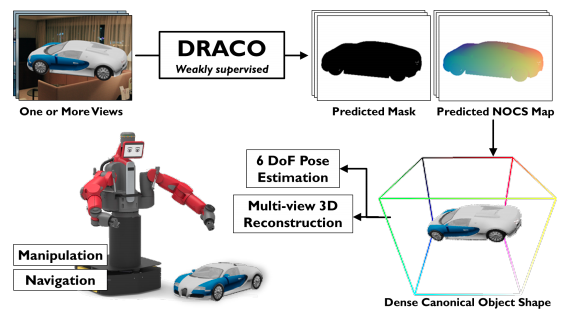
A few representative results from our system - DRACO.

DRACO: Weakly supervised dense reconstruction and canonicalization of objects

Rahul Sajnani * ,  Aadil Mehdi Sanchawala * ,  Krishna Murthy Jatavallabhula ,  Srinath Sridhar ,  and Madhava Krishna K

ICRA 2022

2021

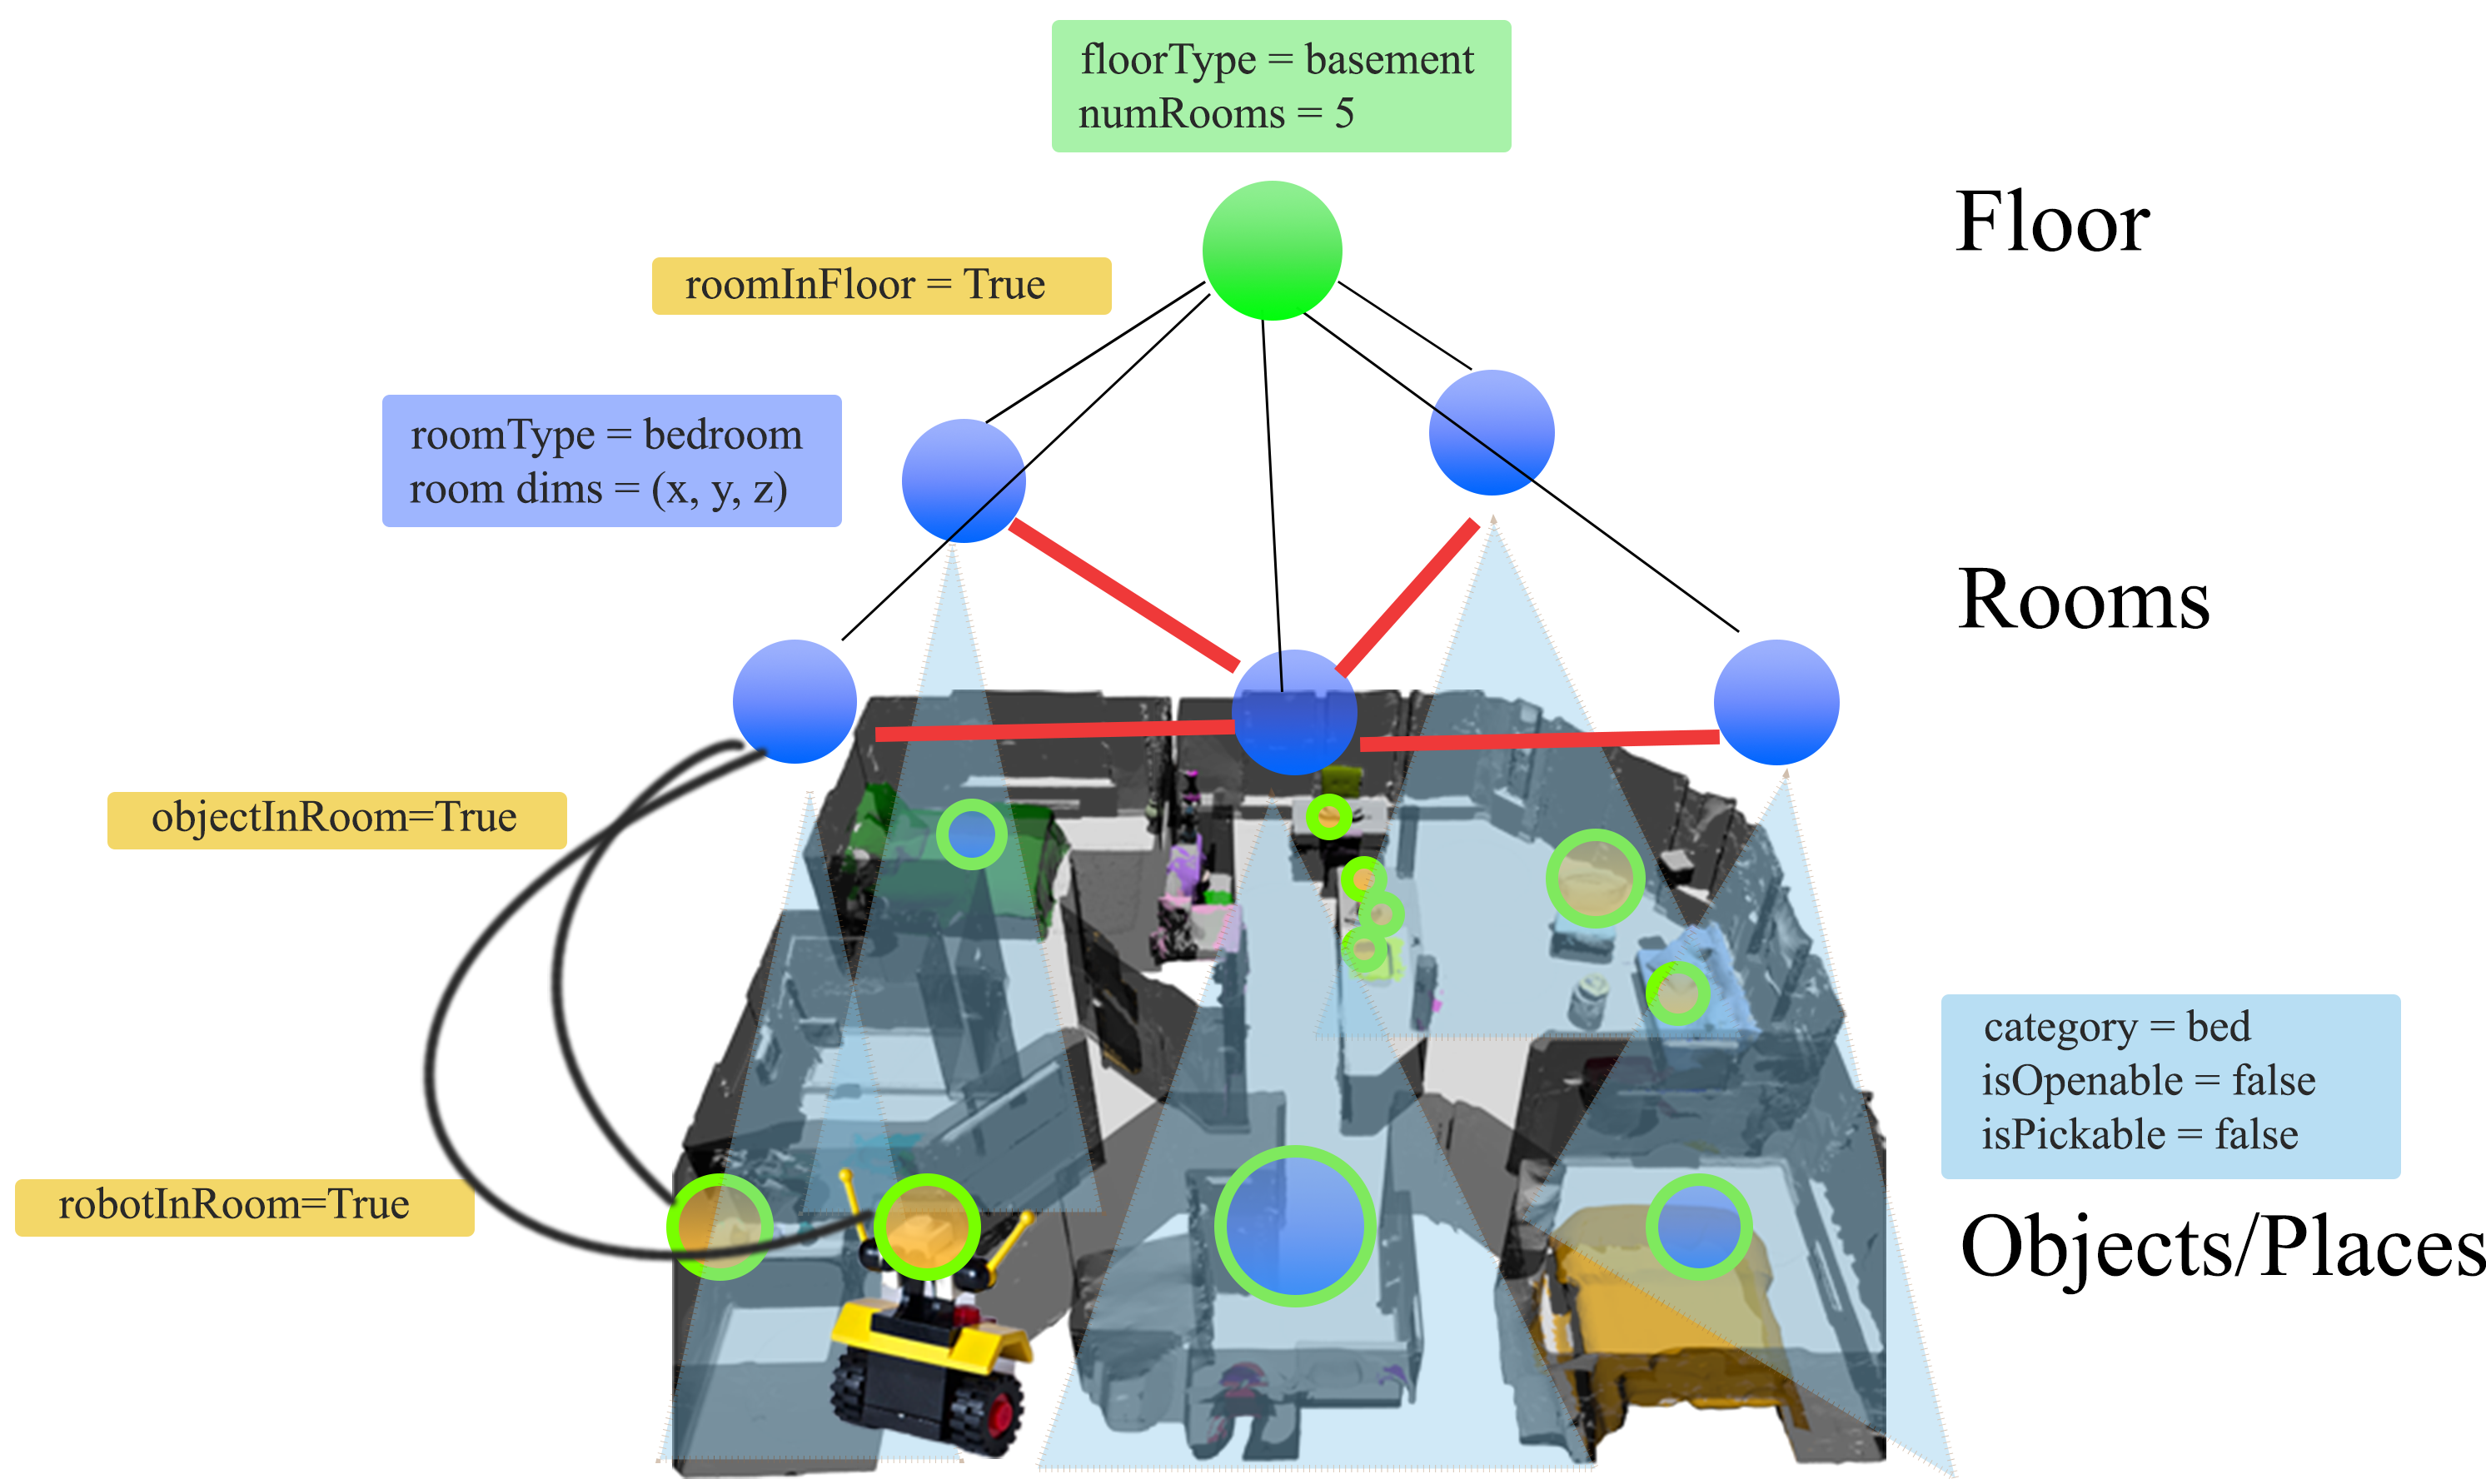
A sample 3D scene graph of a small house containing multiple rooms.

Chris Agia * ,  Krishna Murthy Jatavallabhula * ,  Mohamed Khodeir ,  Ondrej Miksik ,  Vibhav Vineet ,  Mustafa Mukadam ,  Liam Paull ,  and Florian Shkurti

CoRL 2021

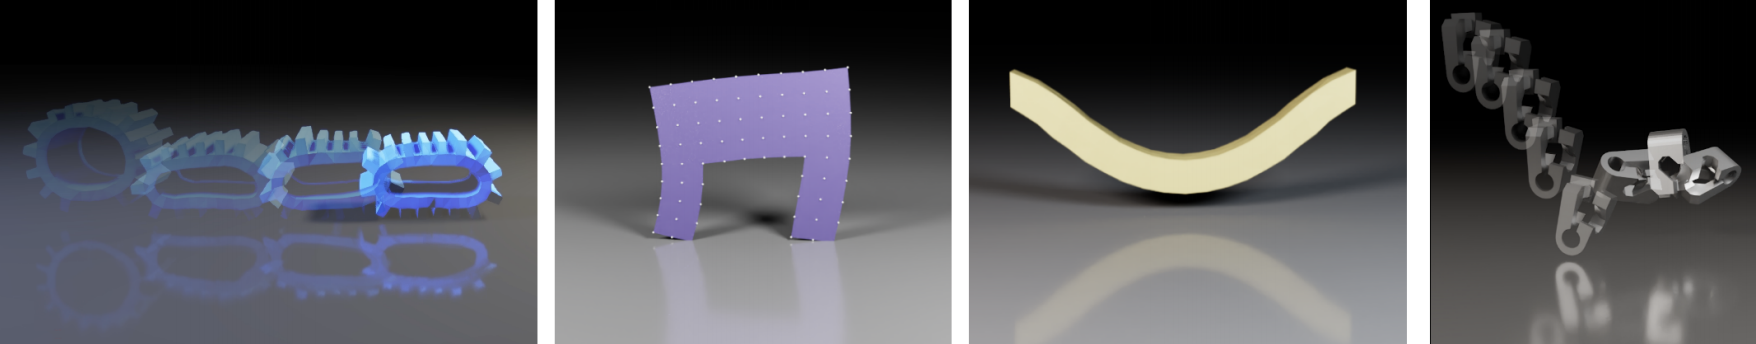
A few physical systems implemented in gradSim.

Krishna Murthy Jatavallabhula * ,  Miles Macklin * ,  Florian Golemo ,  Vikram Voleti ,  Linda Petrini ,  Martin Weiss ,  Breandan Considine ,  Jerome Parent-Levesque ,  Kevin Xie ,  Kenny Erleben ,  Liam Paull ,  Florian Shkurti ,  Derek Nowrouzezahrai ,  and Sanja Fidler

ICLR 2021

2020

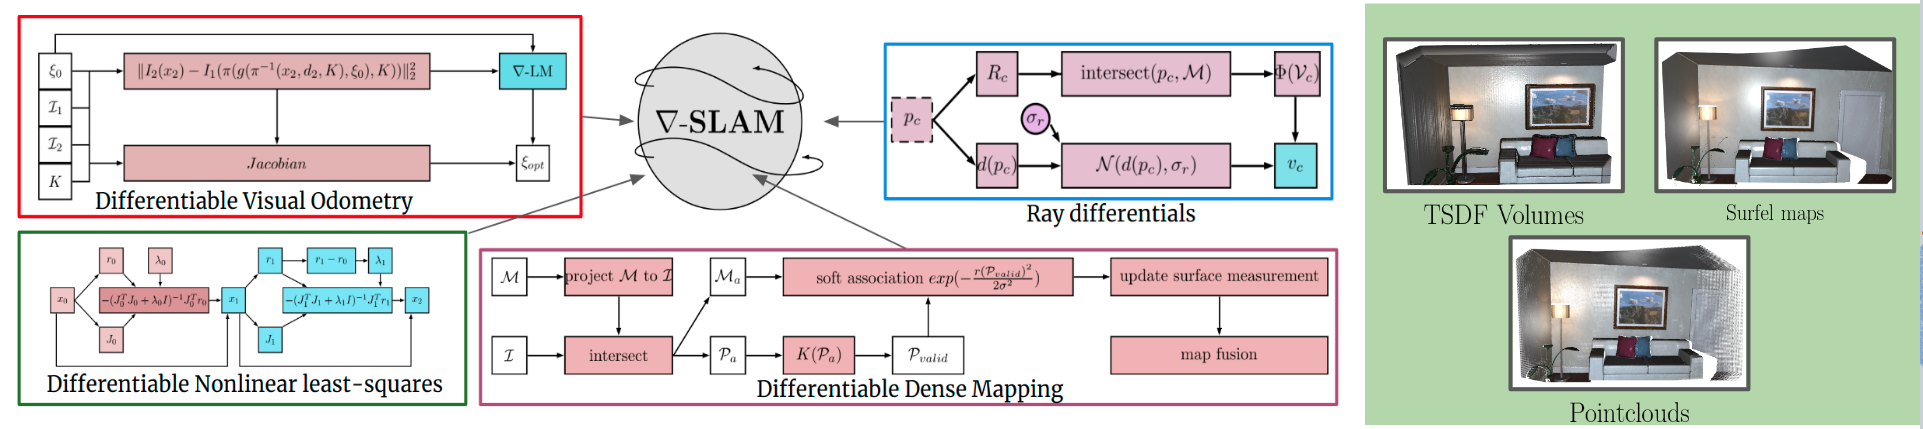
An overview of the various components of gradSLAM

Krishna Murthy Jatavallabhula ,  Ganesh Iyer ,  and Liam Paull

ICRA 2020

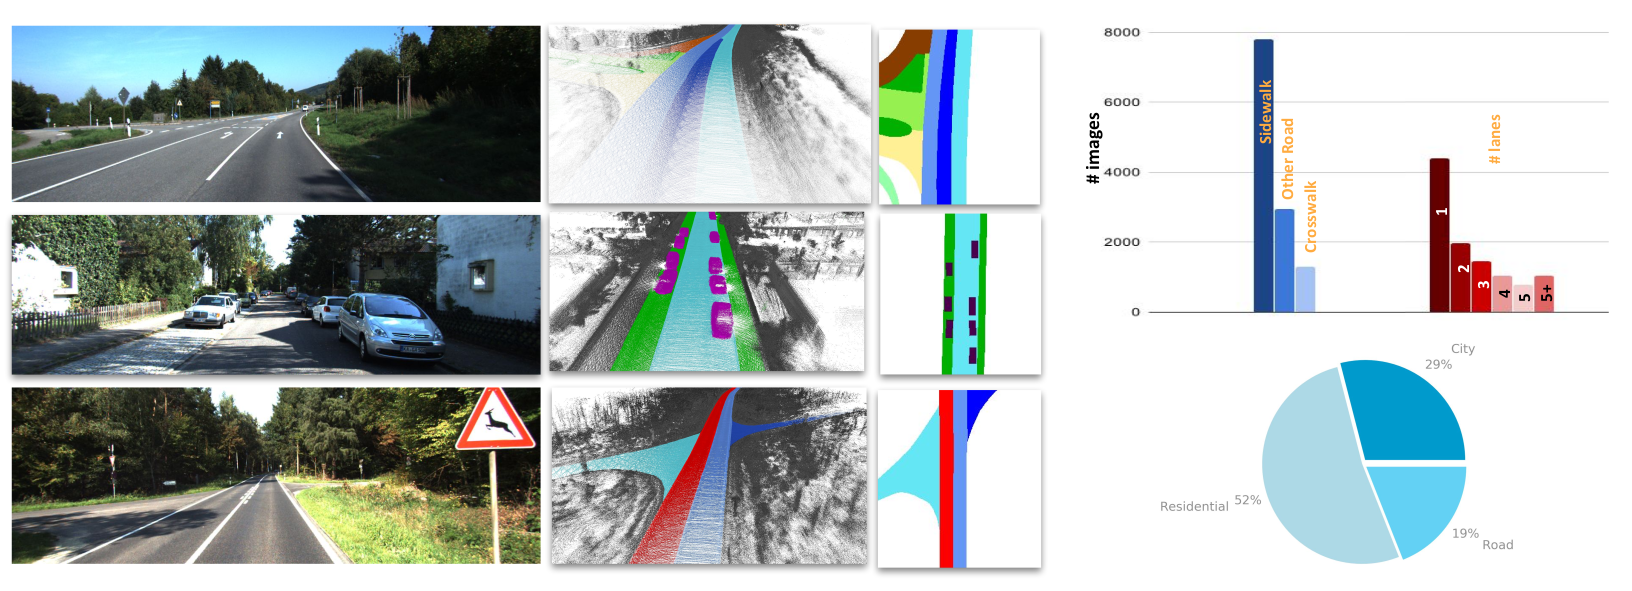
A preview of the AutoLay benchmark for estimating the bird’s-eye view layout of a road scene.

AutoLay: Benchmarking Monocular Layout Estimation

Kaustubh Mani * ,  Sai Shankar * ,  Krishna Murthy Jatavallabhula ,  and Madhava Krishna K

IROS 2020

Bird’s-eye view layouts estimated by MonoLayout.

MonoLayout: Amodal scene layout from a single image

Kaustubh Mani ,  Swapnil Daga ,  Shubhika Garg ,  Sai Shankar ,  Krishna Murthy Jatavallabhula ,  and Madhava Krishna K

WACV 2020

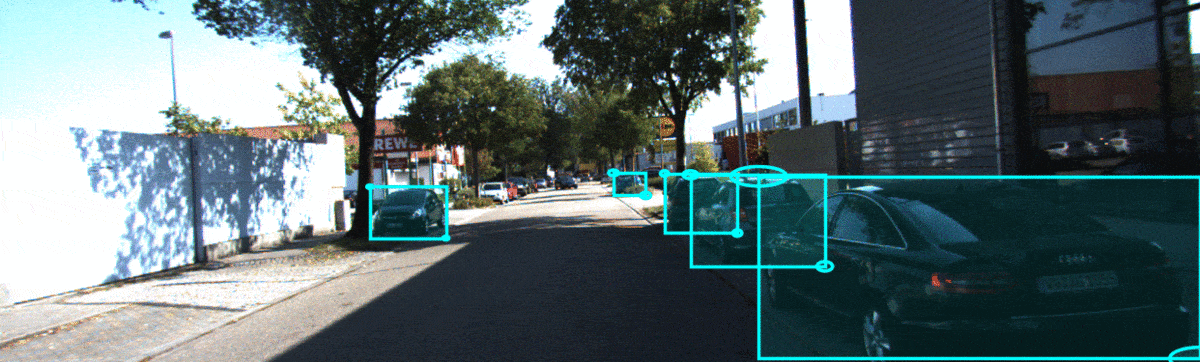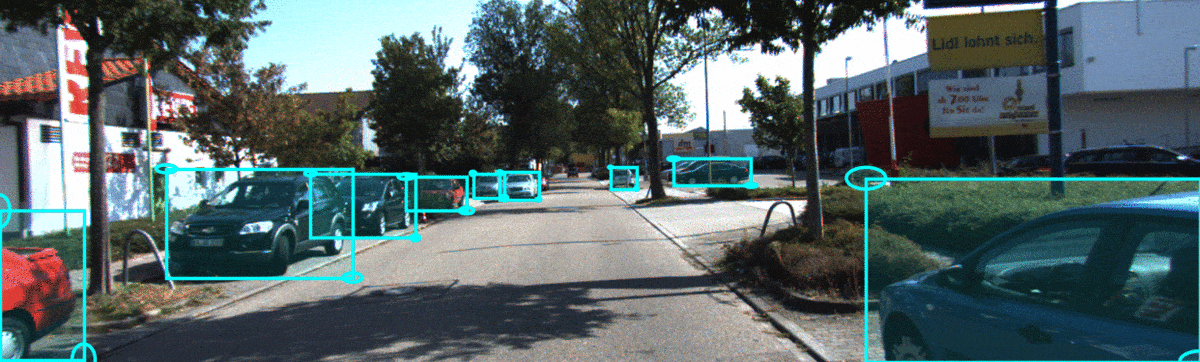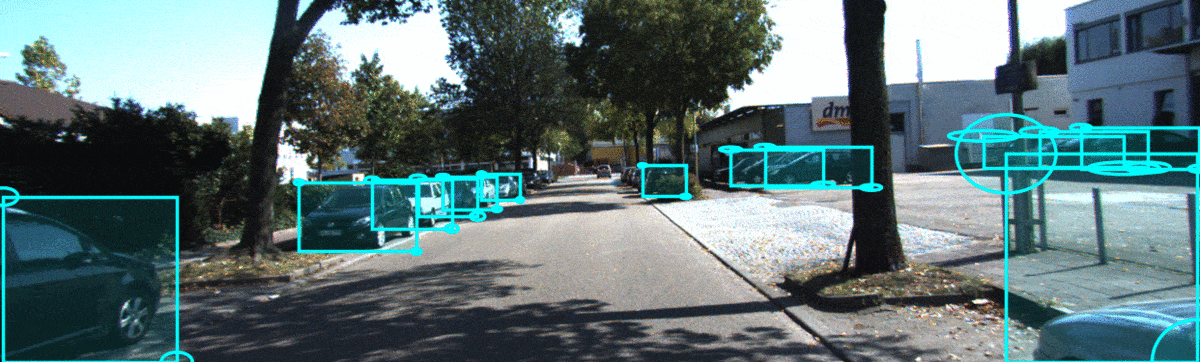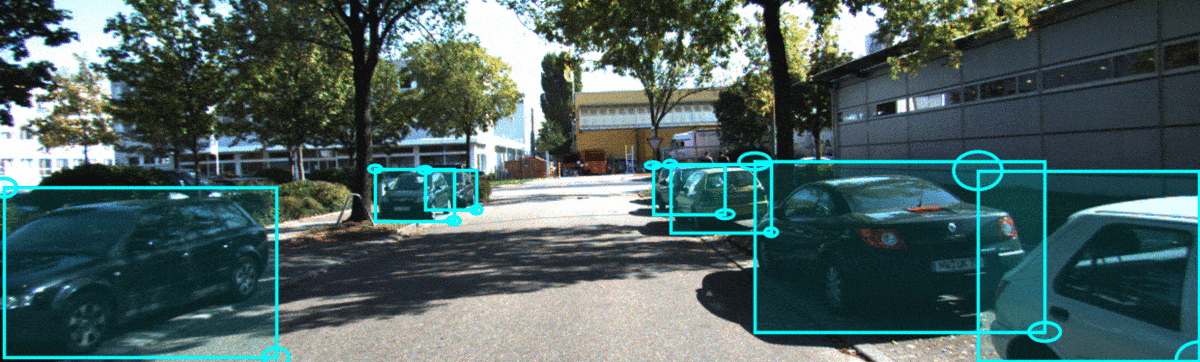
An illustration of our pipeline involving shape and pose optimization of road vehicles.

Multi-object monocular SLAM for dynamic environments

Gokul Nair ,  Swapnil Daga ,  Rahul Sajnani ,  Anirudha Ramesh ,  Junaid Ahmed Ansari ,  Krishna Murthy Jatavallabhula ,  and Madhava Krishna K

Intelligent Vehicles Symposium (IV) 2020

Finalist - Best Student Paper Award

2019

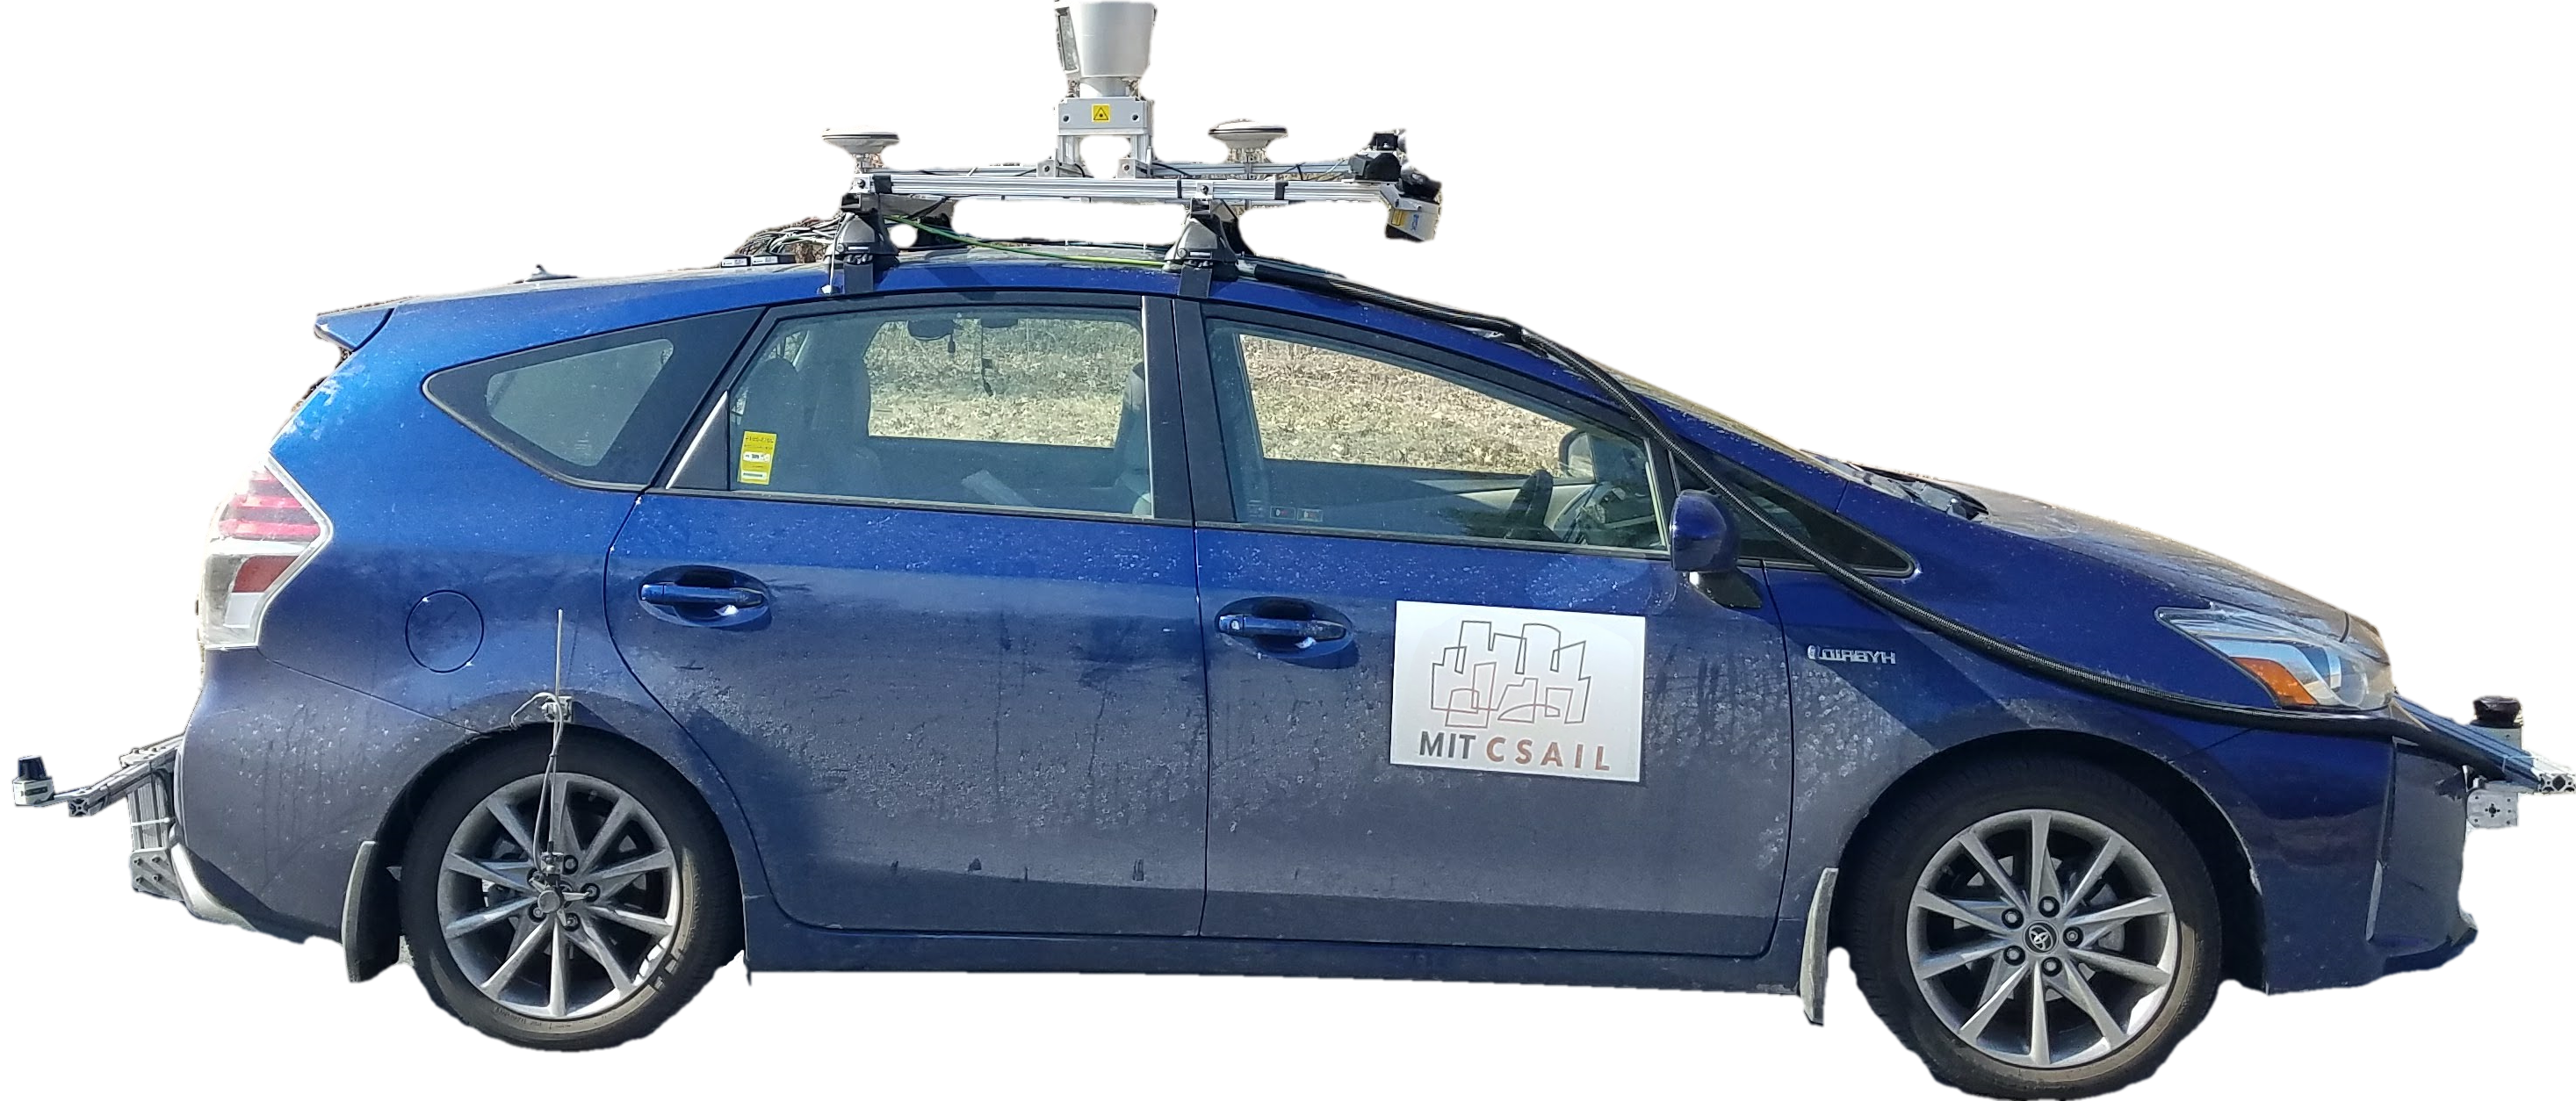
An image of the autonomous car (Toyota Prius V) used for MapLite.

MapLite: Autonomous intersection navigation without detailed prior maps

Teddy Ort ,  Krishna Murthy Jatavallabhula ,  Rohan Banerjee ,  Sai Krishna Gottipati ,  Dhaivat Bhatt ,  Igor Gilitschenski ,  Liam Paull ,  and Daniela Rus

Robotics and Automation Letters 2019

Best paper award

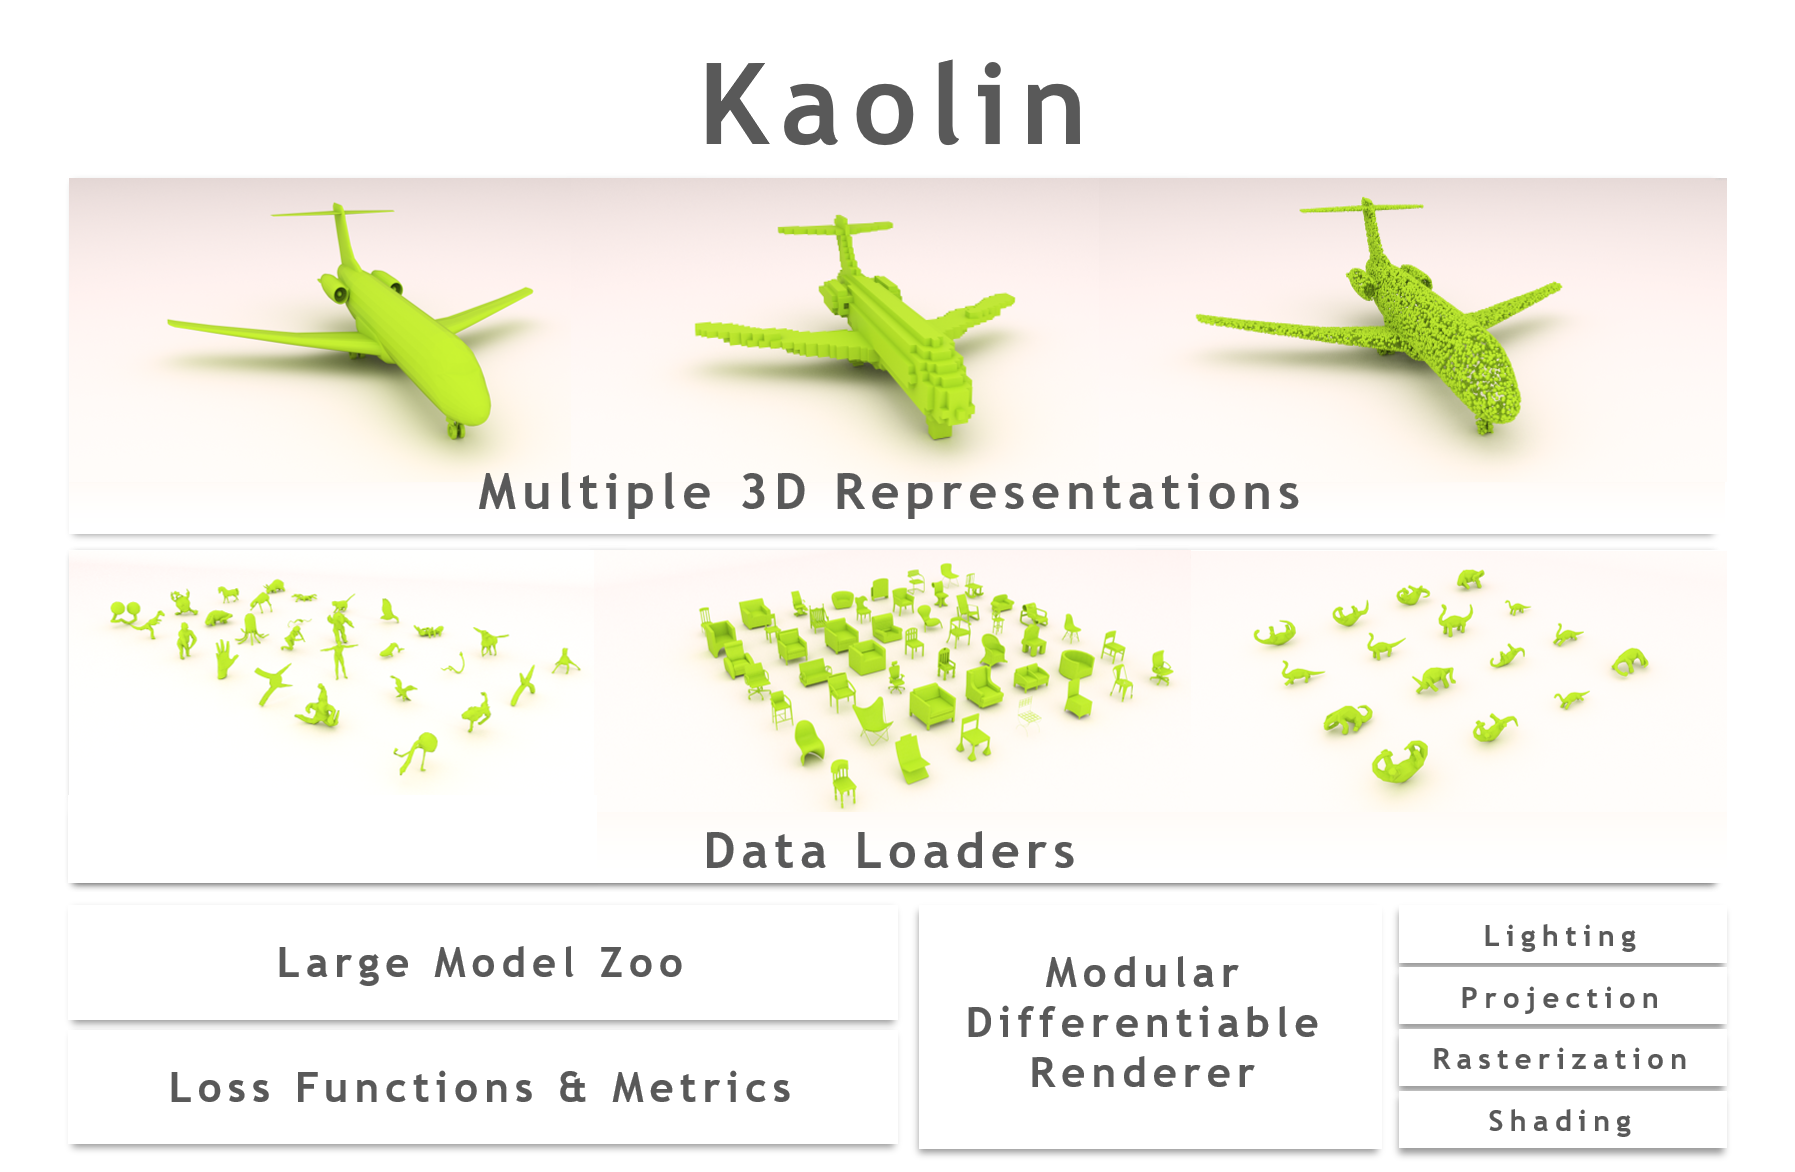
A splash figure showing various features supported by the Kaolin library.

Krishna Murthy Jatavallabhula * ,  Edward Smith * ,  Jean-Francois Lafleche ,  Clement Fuji Tsang ,  Artem Rozantsev ,  Wenzheng Chen ,  Tommy Xiang ,  Rev Lebaredian ,  and Sanja Fidler

Whitepaper 2019

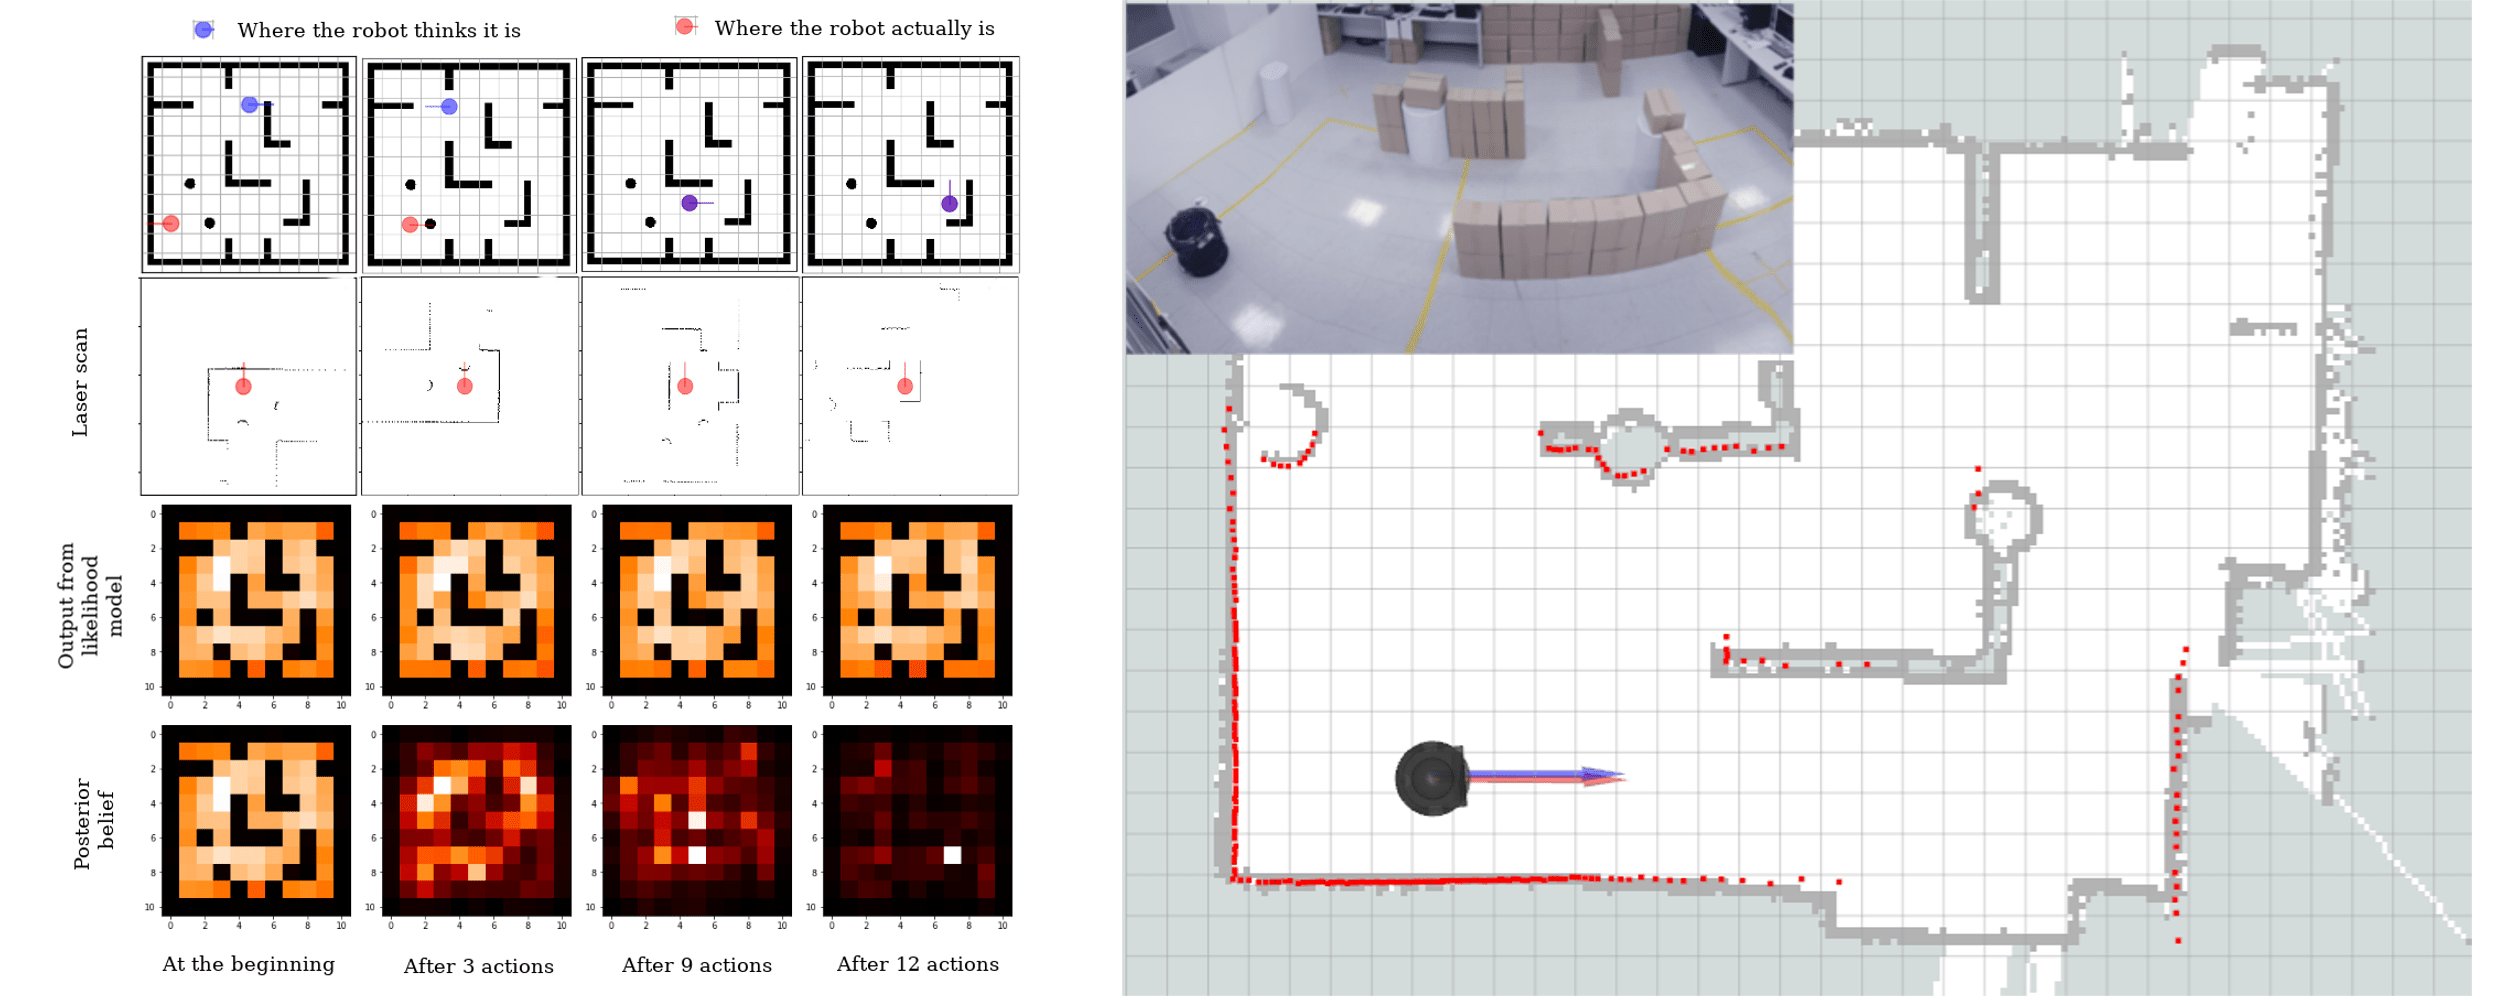
An image of the localization experiments (in simulation and on a real robot).

Deep Active Localization

Sai Krishna Gottipati * ,  Keehong Seo * ,  Krishna Murthy Jatavallabhula ,  Dhaivat Bhatt ,  Vincent Mai ,  and Liam Paull

Robotics and Automation Letters 2019

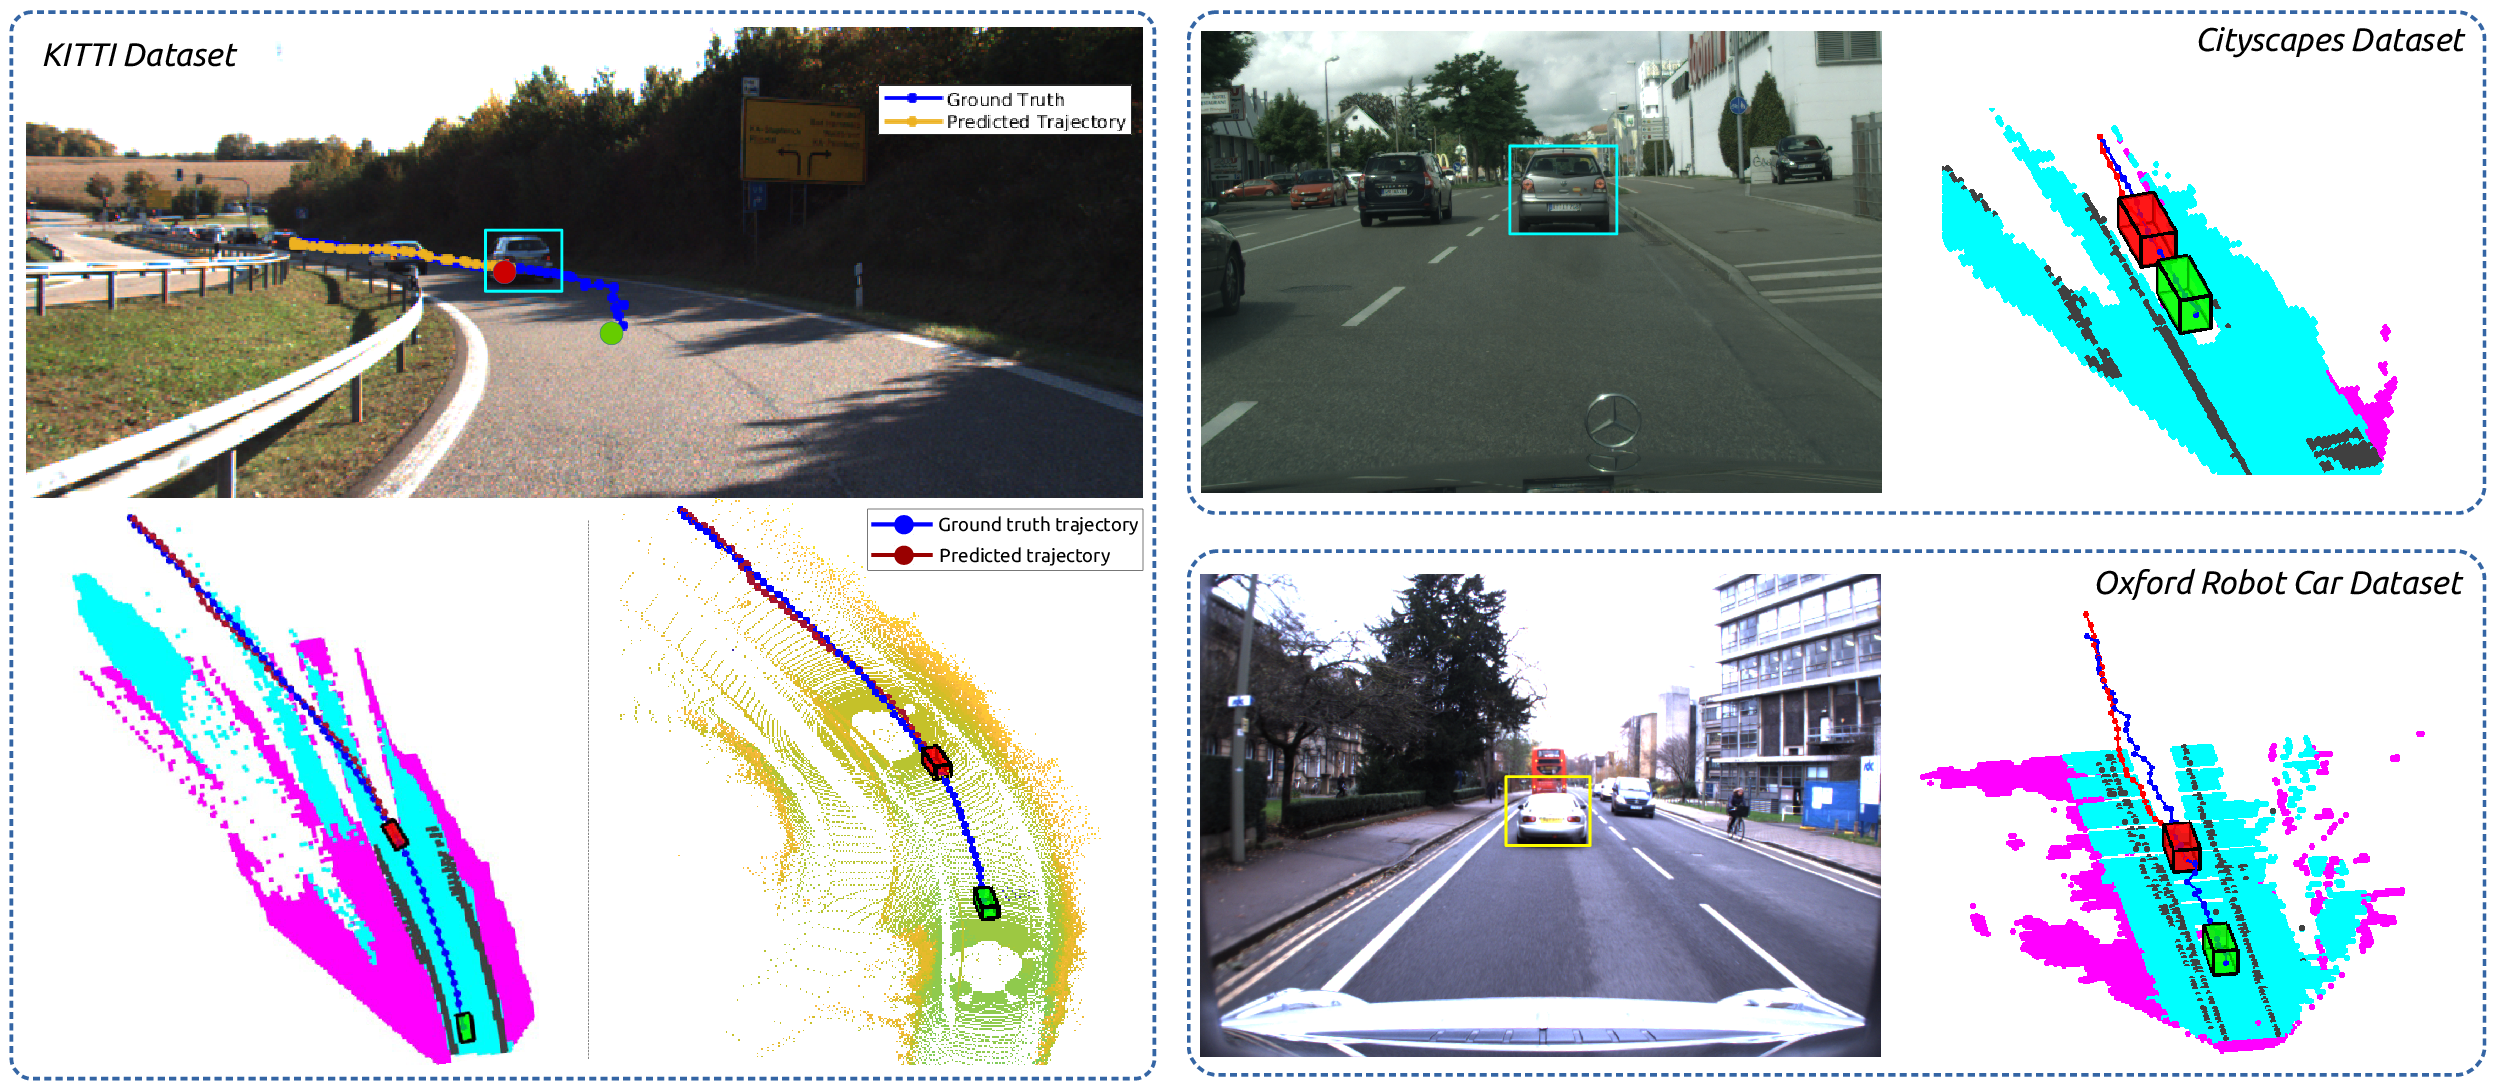
Trajectories forecast in bird’s-eye view by INFER.

INFER: INtermediate representations for FuturE pRediction

Shashank Srikanth ,  Junaid Ahmed Ansari ,  Karnik Ram ,  Sarthak Sharma ,  Krishna Murthy Jatavallabhula ,  and Madhava Krishna K

IROS 2019

2018

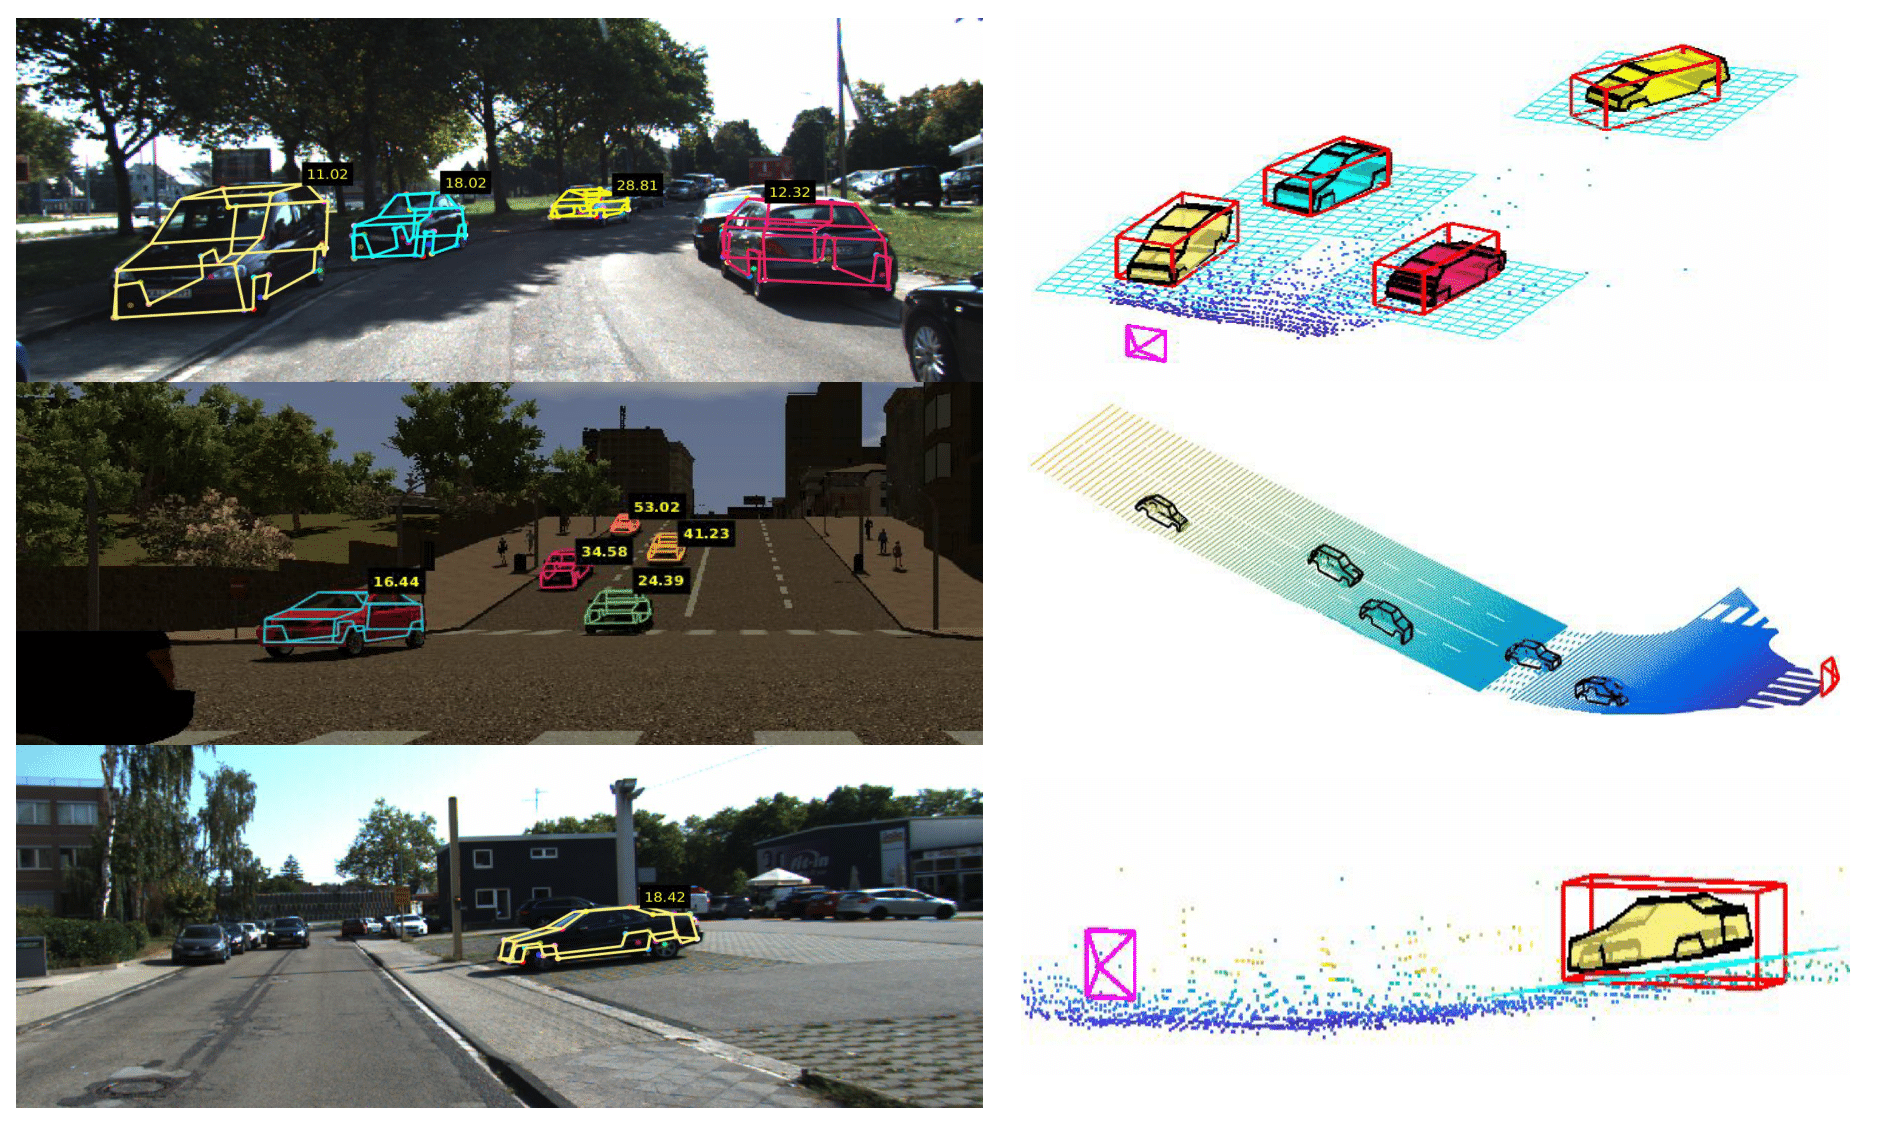
An image showing vehicles on steep and graded roads being reconstructed as wireframes, on synthetic as well as real datasets.

The Earth ain’t Flat: Monocular Reconstruction of Vehicles on Steep and Graded Roads from a Moving Camera

Junaid Ahmed Ansari * ,  Sarthak Sharma * ,  Anshuman Majumdar ,  Krishna Murthy Jatavallabhula ,  and Madhava Krishna K

IROS 2018

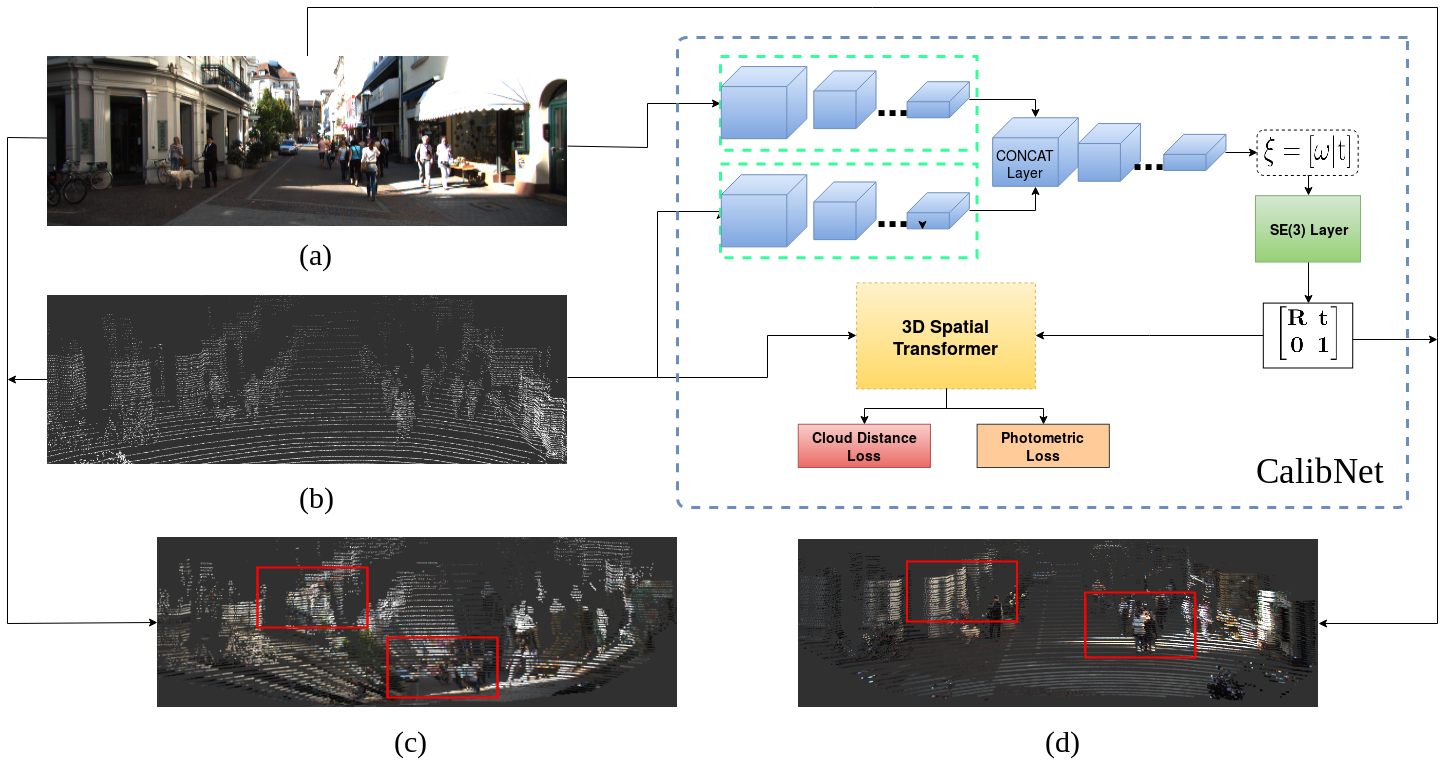
CalibNet architecture (block diagram) for geometrically-supervised lidar-camera extrinsic calibration.

CalibNet: Self-Supervised Extrinsic Calibration using 3D Spatial Transformer Networks

Ganesh Iyer ,  Karnik Ram ,  Krishna Murthy Jatavallabhula ,  and Madhava Krishna K

IROS 2018

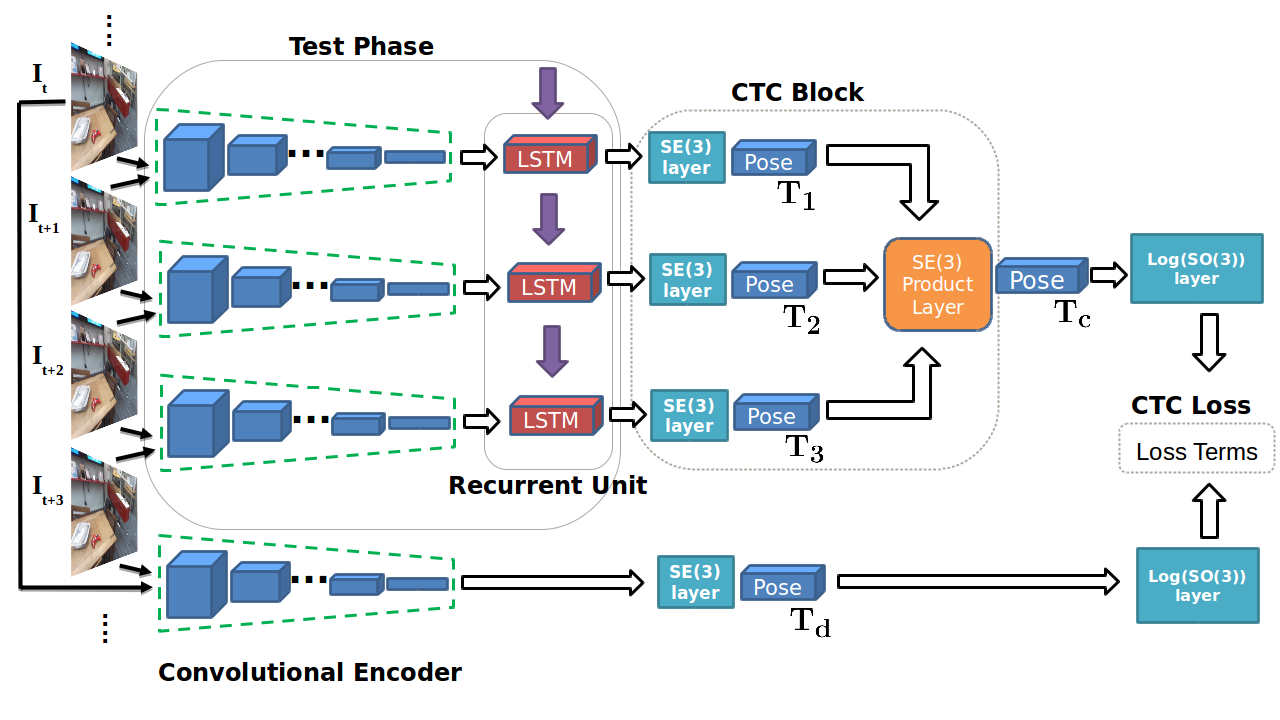
Neural network architecture for geometrically-supervised visual odometry prediction.

Geometric Consistency for Self-Supervised End-to-End Visual Odometry

Ganesh Iyer * ,  Krishna Murthy Jatavallabhula * ,  Gunshi Gupta ,  Madhava Krishna K ,  and Liam Paull

CVPR Workshops 2018

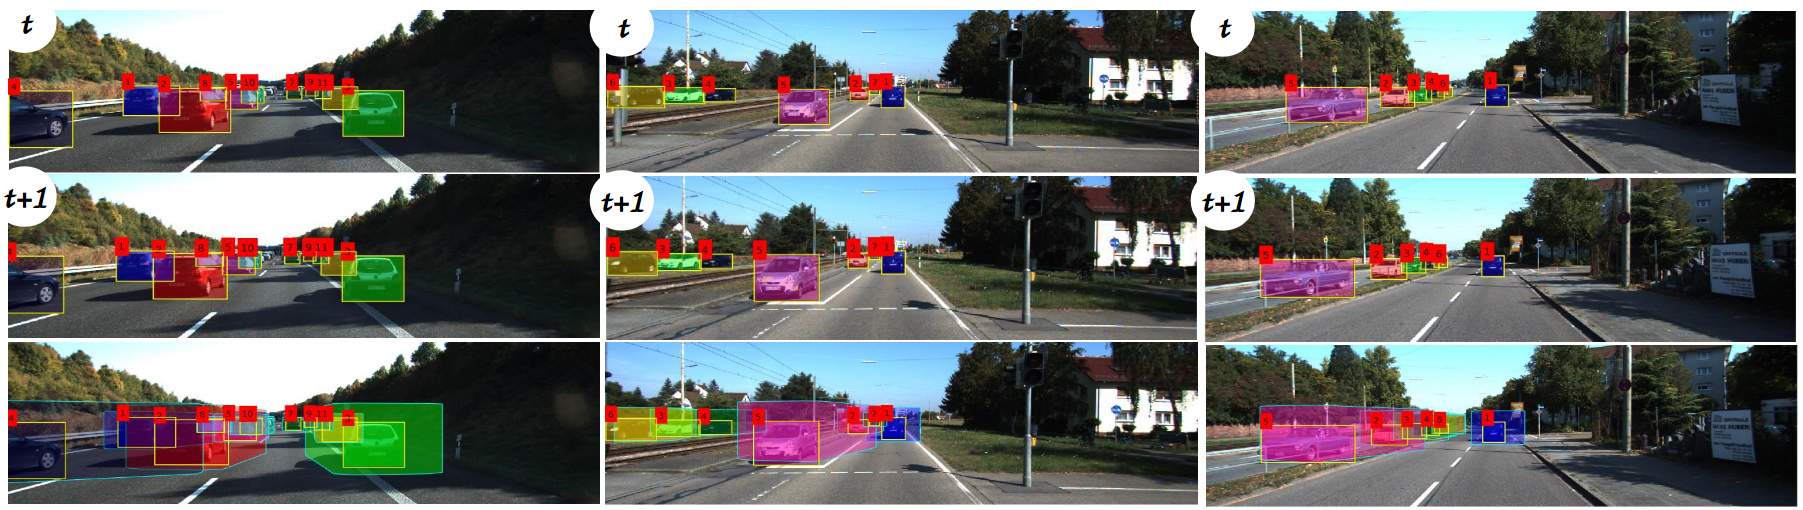
Sample multi-object tracking results from our approach when evaluated on the KITTI dataset.

Beyond Pixels: Leveraging Geometry and Shape Cues for Multi-Object Tracking

Sarthak Sharma * ,  Junaid Ahmed Ansari * ,  Krishna Murthy Jatavallabhula ,  and Madhava Krishna K

ICRA 2018

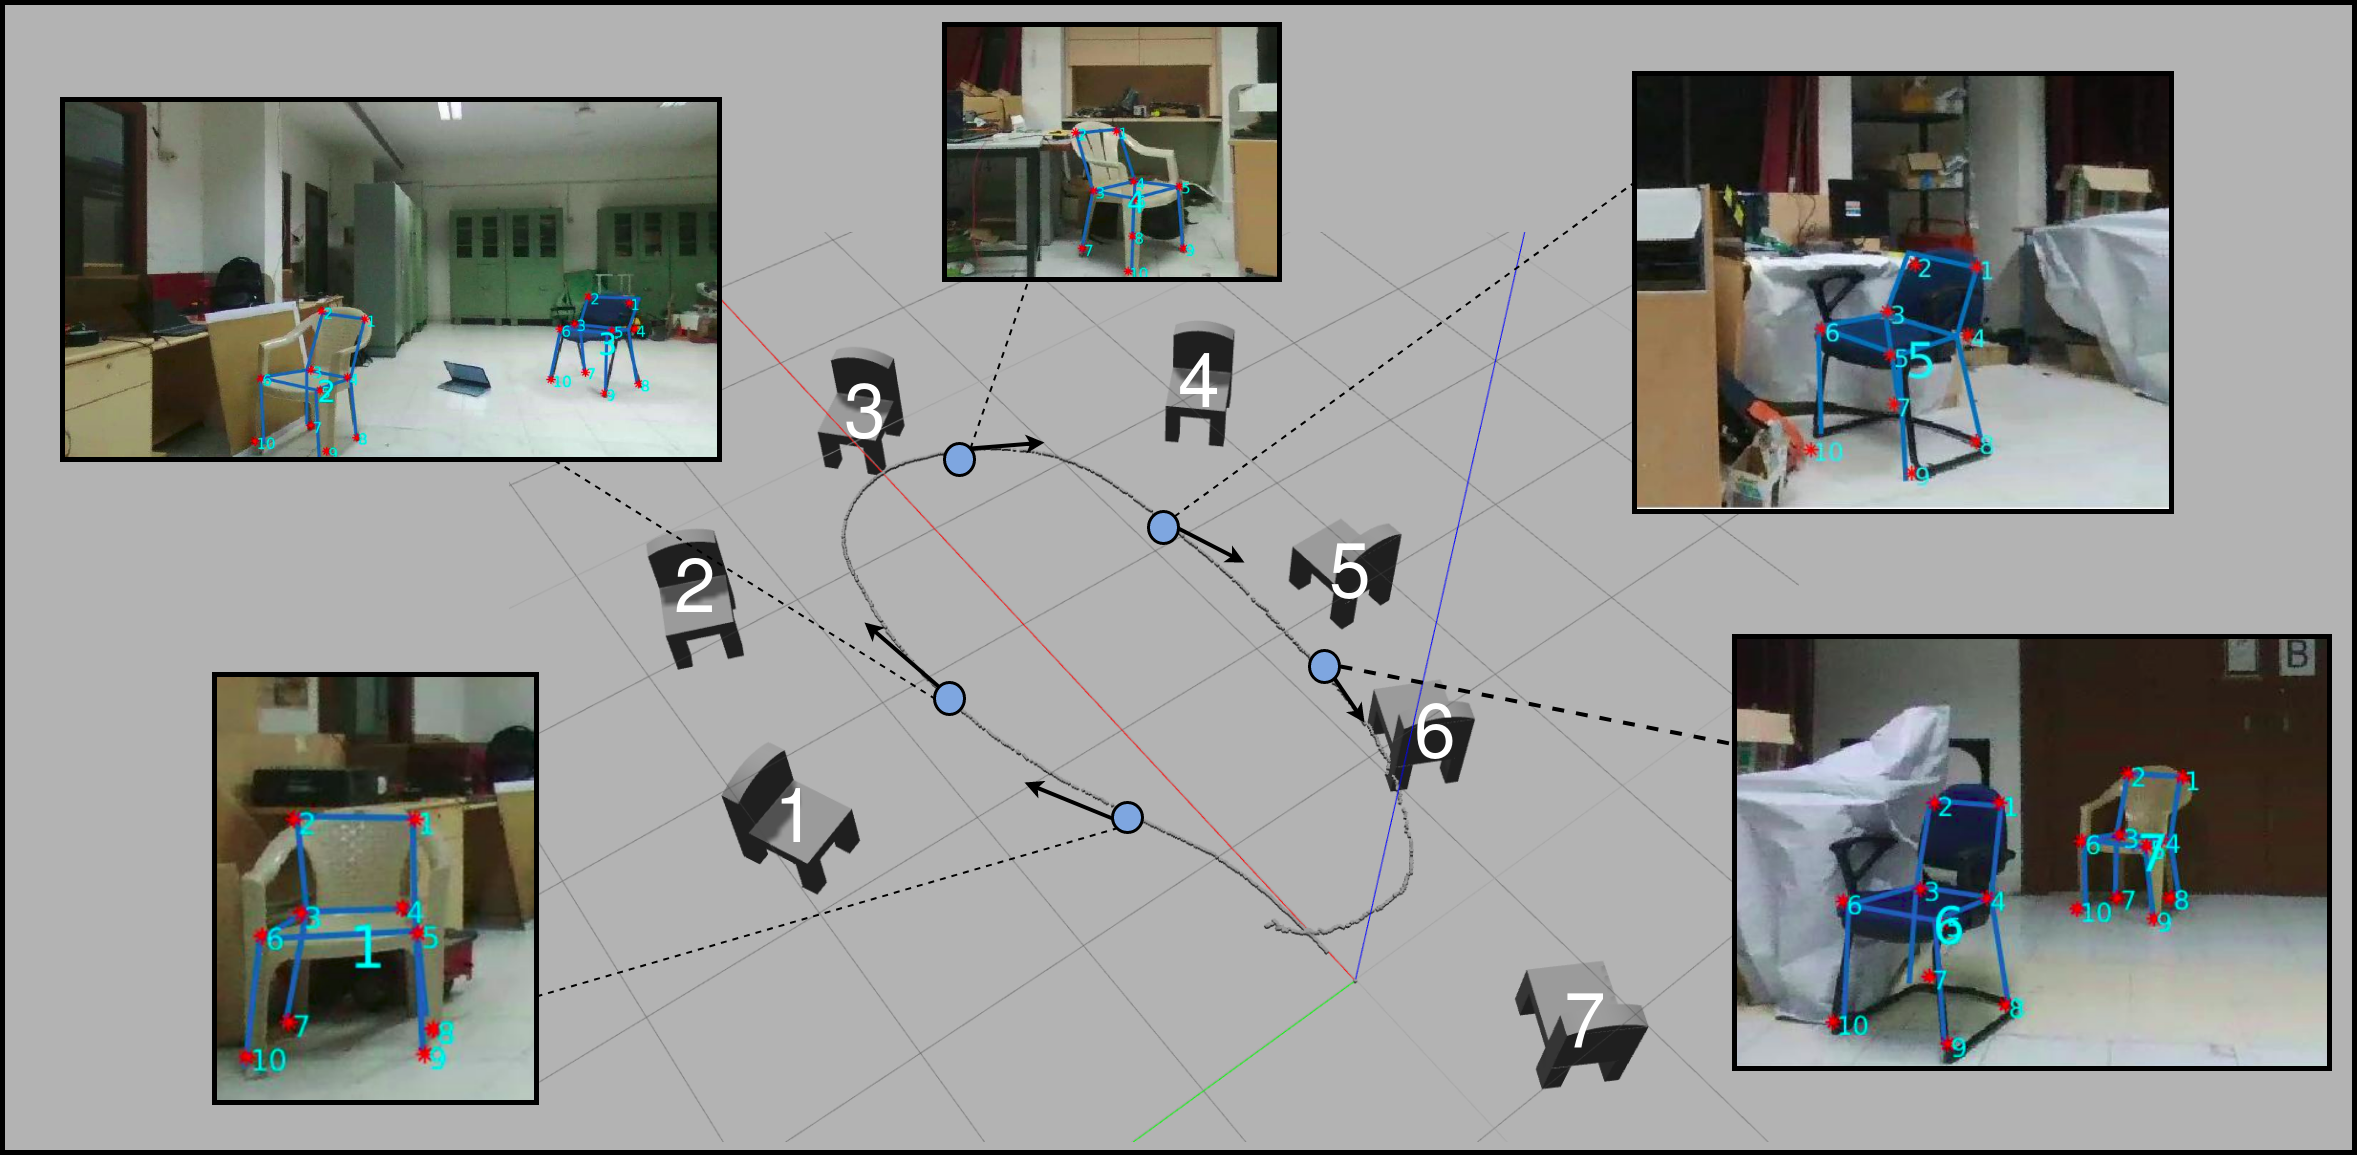
Representative object-SLAM results from the system presented in this paper.

Constructing Category-Specific Models for Monocular Object SLAM

Parv Parkhiya ,  Rishabh Khawad ,  Krishna Murthy Jatavallabhula ,  Madhava Krishna K ,  and Brojeshwar Bhowmick

ICRA 2018

2017

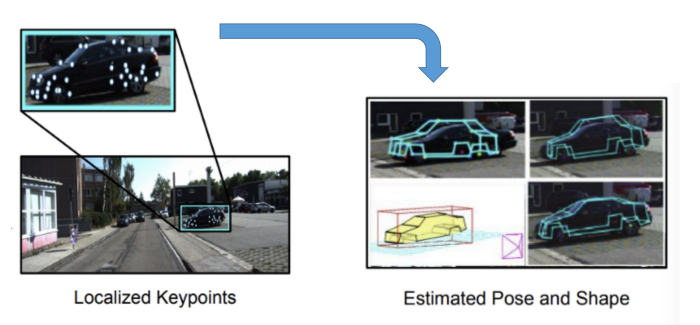
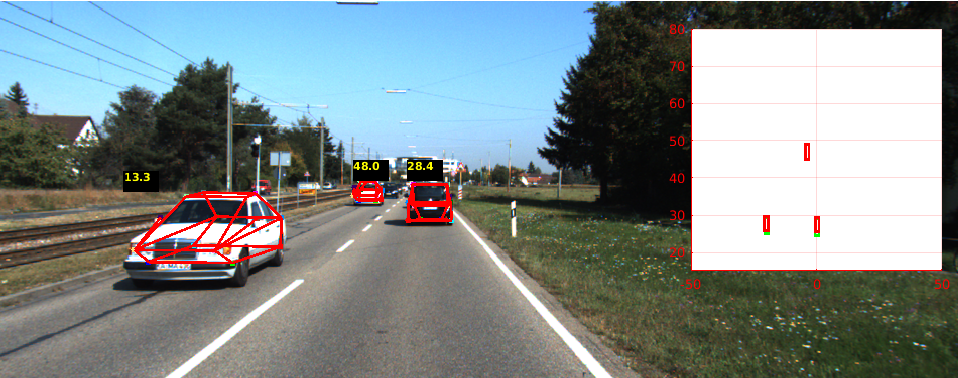
Car wireframes estimated by the method presented in this paper.

Shape Priors for Real-Time Monocular Object Localization in Dynamic Environments

Krishna Murthy Jatavallabhula ,  Sarthak Sharma ,  and Madhava Krishna K

IROS 2017

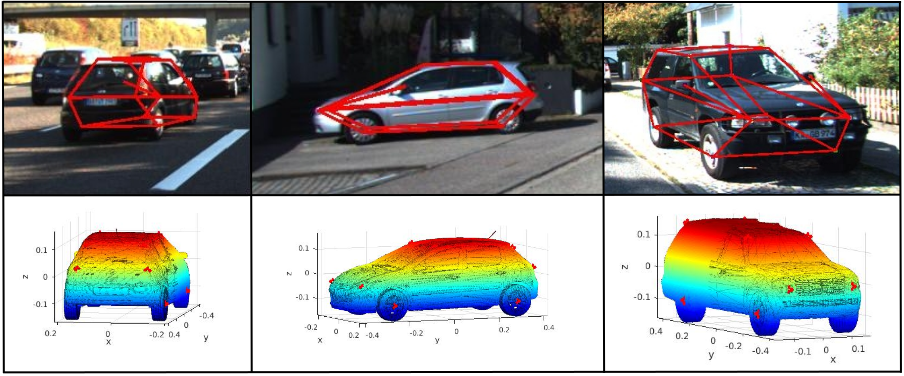
Car wireframes estimated by the method presented in this paper.

Reconstructing Vehicles From a Single Image: Shape Priors for Road Scene Understanding

Krishna Murthy Jatavallabhula ,  Sai Krishna Gottipati ,  Falak Chhaya ,  and Madhava Krishna K

ICRA 2017

2016

JIRS

FAST: Frontier Allocation Synchronized by Token-passing

Avinash Gautam ,  Bhargav Jha ,  Gourav Kumar ,  Krishna Murthy Jatavallabhula ,  Arjun Ram S P ,  and Sudeept Mohan

Springer Journal of Intelligent Robotic Systems 2016

2015

SMC

Cluster, Allocate, Cover: An Efficient Approach for Multi-robot Coverage

Avinash Gautam ,  Krishna Murthy Jatavallabhula ,  Gourav Kumar ,  Arjun Ram S P ,  Bhargav Jha ,  and Sudeept Mohan

IEEE SMC 2015

UKSIM

Maxxyt: An Autonomous Wearable Device for Real-Time Tracking of a Wide Range of Exercises

Danish Pruthi ,  Ayush Jain ,  Krishna Murthy Jatavallabhula ,  and Puneet Teja

UKSIM 2015